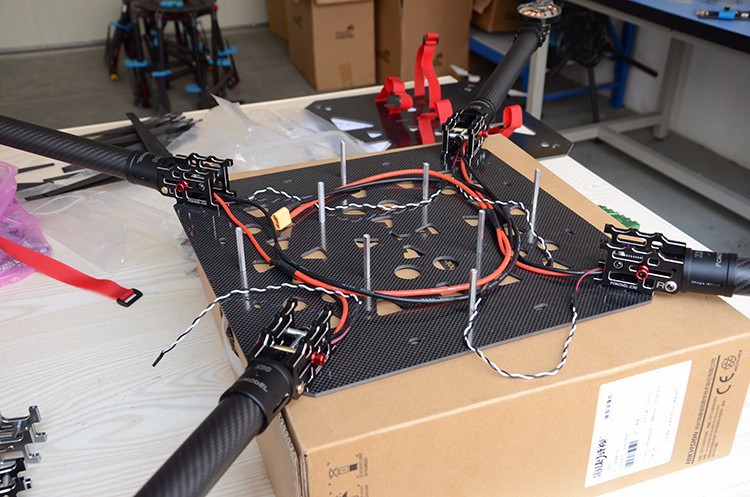

SPIDER Automation | Z30 CNC Aluminium Folding Arm Tube Joint | 30mm Tube Interface & Dual-Screw Multirotor Arm Connector
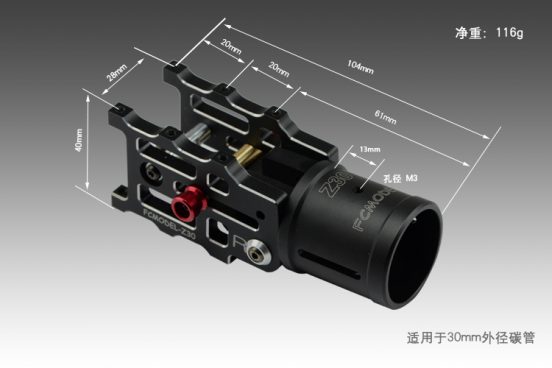
The SPIDER Automation Z30 CNC Aluminium Folding Arm Tube Joint is a mechanical connection component designed for folding-arm structures used in compatible RC quadcopter, hexacopter and multicopter frames. It provides the joint interface between a carbon fibre arm tube and the corresponding frame-side assembly. Its specified dimensions include a 30mm inner diameter, 35mm outer diameter and 112mm length, making dimensional verification essential when selecting it for a particular airframe.
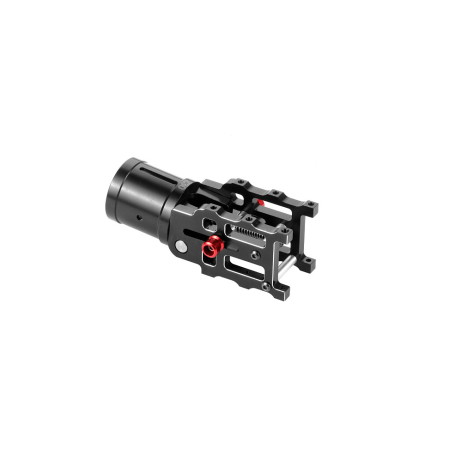
The Z30 design incorporates a CNC-machined aluminium body, an extended square backrest, a dual-screw clamping arrangement, a stainless steel moving shaft and a dual-spring return assembly. The specified 5° upward tilt geometry and 12.9-grade screws form part of its mechanical design. The package contains one joint and one accessories set, including screws intended for centre-plate installation. The required number of joints depends on the number of arms in the multirotor frame.
Product Overview & Mechanical Design
The Z30 is designed to connect a compatible carbon fibre tube arm to a folding-arm frame assembly. Its mechanical structure combines the tube-clamping section, extended backrest, moving shaft and spring-return components into one joint assembly.
The extended square backrest provides an enlarged support arrangement at the joint interface. The design is intended to improve contact between the connected components and reduce unwanted clearance or movement associated with an inadequately seated joint. Actual fitment depends on the tube dimensions, joint geometry and correct fastener installation.
CNC Aluminium Body & Dual-Screw Clamping Structure
The joint body uses CNC-machined aluminium construction and incorporates a dual-screw clamping arrangement. The two-screw structure is intended to secure the compatible carbon fibre tube and folding-joint interface more closely than a single-point clamping arrangement.
- CNC-Machined Aluminium: Forms the main structural body of the folding arm joint.
- Dual-Screw Clamping: Uses two screws to secure the compatible tube and joint interface.
- Extended Square Backrest: Provides an extended support section at the joint assembly.
- Tube Interface: The stated 30mm inner diameter is a key dimension to check against the intended arm-tube fitment.
- Frame-Side Connection: Includes screws for installation at the corresponding centre plate.
Stainless Steel Moving Shaft & Dual Spring Return
The Z30 joint uses a stainless steel moving shaft in place of the copper shaft used in an earlier design. The shaft forms the moving mechanical connection within the folding-joint assembly.
A dual-spring return arrangement provides spring force within the joint mechanism. The springs work as part of the folding assembly, while the moving shaft provides the pivot connection. The actual folding movement, spring preload and mechanical operating range depend on the joint’s construction and installation.
- Stainless Steel Pivot Shaft: Provides the moving shaft component of the joint assembly.
- Dual Spring Arrangement: Incorporates two return springs within the folding mechanism.
- Mechanical Pivot Connection: Supports the moving connection between the joint sections.
- Fastener Assembly: Uses the supplied screws to assemble and secure the joint components.
5° Upward Tilt Geometry
The Z30 folding arm joint incorporates a specified 5-degree upward tilt in its geometry. This provides an angled arm connection when installed in the intended frame orientation. The 5° value describes the specified joint geometry and should not be interpreted as an adjustable angular range.
During frame design or replacement, check the installed orientation and resulting arm alignment against the airframe’s mechanical layout.
12.9-Grade Fasteners & Centre-Plate Installation
The joint assembly uses 12.9-grade screws, a high-strength fastener grade used in mechanical assemblies. Additional screws are supplied for centre-plate installation, allowing the joint to be integrated with a compatible frame-side mounting arrangement.
Fastener size, thread specification, tightening torque and centre-plate hole dimensions are not established by the available product specifications. These details should be checked against the actual joint and frame before installation.
Dimensional Fitment & Frame Compatibility
The Z30 is intended for compatible folding-arm RC quadcopter, hexacopter and multicopter structures. The stated 30mm inner diameter and 35mm outer diameter are important dimensions for assessing tube and assembly fitment. However, the complete clamping profile, insertion depth and frame-side mounting geometry must also match the intended airframe.
Verify the actual tube outside diameter, clamping profile, joint orientation, centre-plate hole arrangement and available installation clearance before purchasing or assembling the component. The product should not be treated as a universal replacement for every 30mm-class folding arm joint.
Applications
The Z30 CNC aluminium folding arm tube joint is intended for mechanical integration in compatible folding-arm multirotor structures.
- RC Quadcopter Frames: Folding-arm connection for compatible four-arm multirotor structures.
- RC Hexacopter Frames: Mechanical arm-joint integration in compatible six-arm airframes.
- RC Octocopter Frames: Arm connection for compatible eight-arm multirotor configurations.
- Carbon Fibre Tube Arms: Clamping and joint integration with dimensionally compatible carbon fibre tubes.
- Folding Multirotor Structures: Mechanical connection for airframes designed around folding arm assemblies.
- Frame Fabrication: Integration into custom multirotor frame structures with matching tube and centre-plate geometry.
- Airframe Maintenance: Replacement of a worn or damaged compatible folding arm joint.
- Multirotor Frame Modification: Mechanical integration in compatible frame redesigns and arm-assembly projects.
Package Includes
- 1 × Z30 CNC Aluminium Folding Arm Tube Joint (Round-Head Single Screw Version)
- 1 × Accessories Set
Quantity planning: One joint is required per arm. A four-arm quadcopter requires four joints, a six-arm hexacopter requires six joints and an eight-arm octocopter requires eight joints. The supplied package contains only one joint and one accessories set.
Product Specifications
| Parameter | Specification |
|---|---|
| Product Model | Z30 |
| Product Type | CNC Aluminium Folding Arm Tube Joint |
| Main Body Material | Aluminium |
| Outer Diameter (OD) | 35mm |
| Inner Diameter (ID) | 30mm |
| Length | 112mm |
| Width | 58mm |
| Height | 40mm |
| Product Weight | 145g |
| Clamping Structure | Dual-Screw Clamping Arrangement |
| Backrest Design | Extended Square Backrest |
| Moving Shaft Material | Stainless Steel |
| Spring Arrangement | Dual Spring Return |
| Fastener Grade | 12.9 Grade Screws |
| Arm Tilt Geometry | 5° Upward Tilt |
| Frame Installation | Centre-Plate Screw Installation |
| Intended Frame Types | Compatible RC Quadcopter, Hexacopter and Multicopter Frames |
| Package Quantity | 1 Joint |
| Included Accessories | 1 Accessories Set |
Installation & Operating Recommendations
- Verify Tube Dimensions: Confirm that the carbon fibre arm tube matches the joint’s actual internal clamping geometry. Do not rely on the nominal 30mm inner-diameter value alone without checking the fit.
- Check Frame-Side Compatibility: Verify centre-plate dimensions, mounting-hole positions and screw clearance before installing the joint.
- Inspect Joint Components: Check the aluminium body, stainless steel moving shaft, springs and supplied fasteners for damage or deformation before assembly.
- Align the Clamping Interface: Position the tube correctly within the joint and ensure that the clamping surfaces make proper contact before tightening.
- Tighten Clamping Screws Evenly: Tighten both screws progressively to maintain balanced clamping. Avoid excessive force that could damage the carbon fibre tube or joint threads.
- Check Pivot Movement: Confirm that the moving shaft and spring-return mechanism operate without binding or abnormal play after installation.
- Verify Arm Orientation: Install the joint in the intended orientation and check the specified 5° upward tilt against the airframe geometry.
- Inspect Fasteners: Check screw seating and joint alignment periodically, particularly after transport, maintenance or mechanical impact.
- Check Folding Clearance: Confirm that the installed arm can move through its intended folding path without interference with the frame, wiring or adjacent components.
- Perform a Pre-Operation Inspection: Verify tube retention, centre-plate fastening, pivot movement and spring condition before operating the multirotor.