
SPIDER Automation 2-DOF Robotic Manipulator Claw | Aluminum Alloy End-Effector
Description
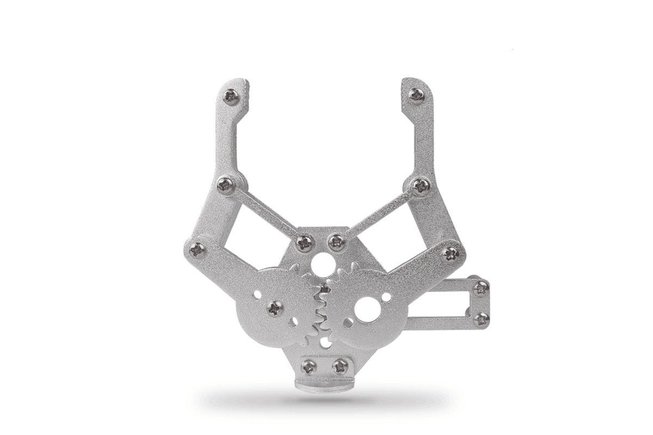
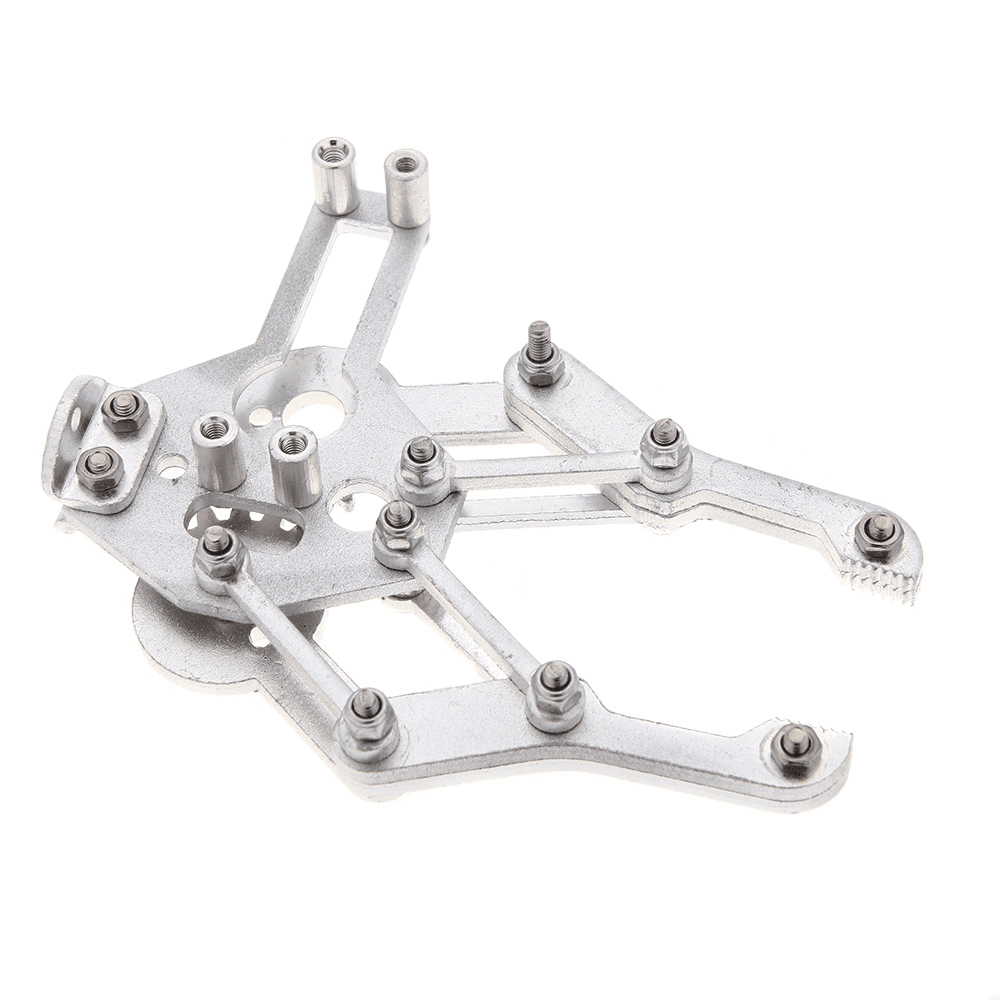
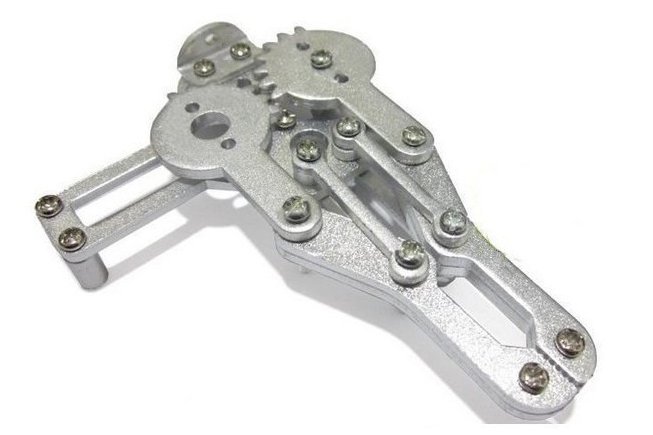
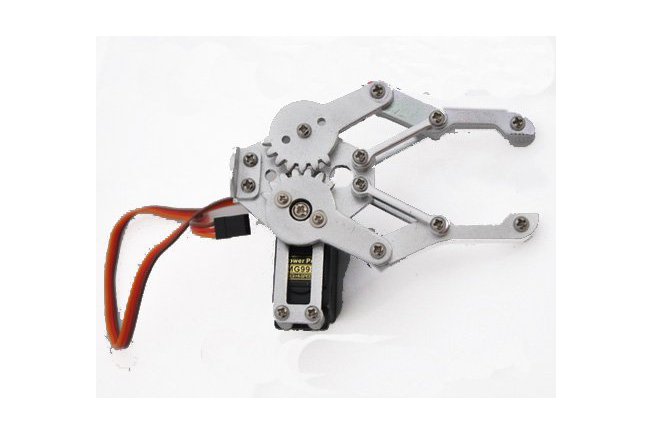
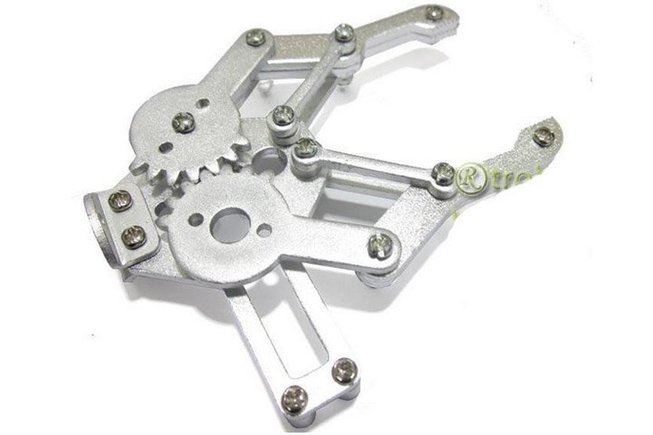
Build professional-grade pick-and-place systems, automated sorting lines, or custom articulated robotic arms with the SPIDER Automation 2-DOF Aluminum Alloy Robotic Manipulator Gripper Claw. Designed for reliability and structural precision, this mechanical end-effector features a durable, lightweight aluminum alloy frame that resists mechanical fatigue and torsion during repetitive operational cycles. Fully compatible with standard MG995 high-torque servos, it delivers dependable grip pressure and smooth angular articulation, making it an essential hardware component for engineers, makers, and robotics development labs.
Key Features
- Variable Jaw Opening Geometry: Delivers a default 55 mm maximum opening span without expansion boards, extending up to a wide 95 mm configuration with auxiliary plates installed.
- Lightweight Aluminum Alloy Construction: High-grade metallic chassis provides an exceptional strength-to-weight ratio, ensuring minimal inertia on the final rotational axis of your robotic arm.
- Direct Servo Integration: Precision-drilled mounting slots engineered to interface seamlessly with popular MG995 and compatible high-torque servo motors.
- Optimized 2-DOF Kinematics: Designed with two degrees of freedom to enable both secure gripping actions and rotational positioning flexibility.
- Precision Dimensional Profile: Features a total closed length of 108 mm and a maximum open width of 98 mm for clean geometric calculations during kinematics software programming.
Benefits
- Robust Payload Capacity: Safely grips, lifts, and relocates objects weighing up to 500 grams without mechanical slippage or structural flex.
- Enhanced Durability: All-metal aluminum construction significantly outlasts standard 3D-printed or plastic gripper jaws under continuous workloads.
- Flexible Prototyping: Easily mounts to multi-axis robotic arms, gantry systems, or mobile robotic chassis for diverse functional roles.
- Cost-Effective Automation: Provides industrial-grade mechanical gripping performance at an accessible price point for custom builds.
- Precise Object Handling: Synchronized finger movement ensures balanced, centered clamping force on cylindrical, rectangular, or irregular payloads.
- Easy Assembly: Straightforward mechanical layout allows rapid integration with standard servo horns and fastening hardware.
Applications
- Pick-and-Place Robotic Arms: Material transfer stations on automated laboratory benches and small-scale production assembly lines.
- STEM & Mechatronics Education: Teaching students advanced robotics, kinematics, inverse calculations, and automated sorting algorithms.
- Laboratory Automation: Automated sample tube handling, container shifting, and specimen sorting in testing environments.
- Search and Rescue Rovers: Remote-controlled manipulator claws utilized for obstacle clearing and delicate object retrieval.
- Warehouse Logistics Prototyping: Small-scale parcel sorting, box handling, and inventory management proof-of-concept models.
- Custom Automated Jigs: Part-clamping end-effectors designed for automated CNC workstations or custom testing fixtures.
Package Includes
- 1 x Robot Manipulator Mechanical Arm Metal Claws (Normal Quality Build)
Specifications
| Parameter | Specification |
|---|---|
| Item Type | Mechanical Robotic Gripper Claw / End-Effector |
| Brand | SPIDER Automation |
| Degrees of Freedom (DOF) | 2 DOF |
| Max Paw Opening Angle | 55 mm (Base) / Up to 95 mm (with Extension Board) |
| Claw Material | Aluminum Alloy |
| Compatible Servo Motor | MG995 Series High-Torque Servos |
| Payload Capacity | Up to 500 g |
| Claw Dimensions (Closed) | 108 mm (Length) x 98 mm (Width) |
| Claw Weight (Without Motor) | Approx. 68 g |
| Shipping Weight | 0.1 kg |
| Shipping Dimensions | 10 x 6 x 4 cm |