
SPIDER Automation Mamba F405 Flight Controller & REV35 35A 4-in-1 ESC Stack | 2–6S LiPo FPV Drone Powertrain Control System
Description
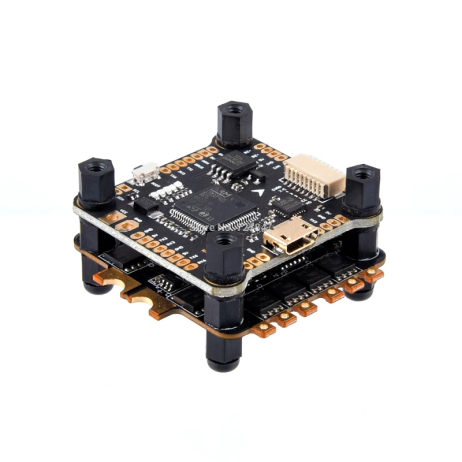
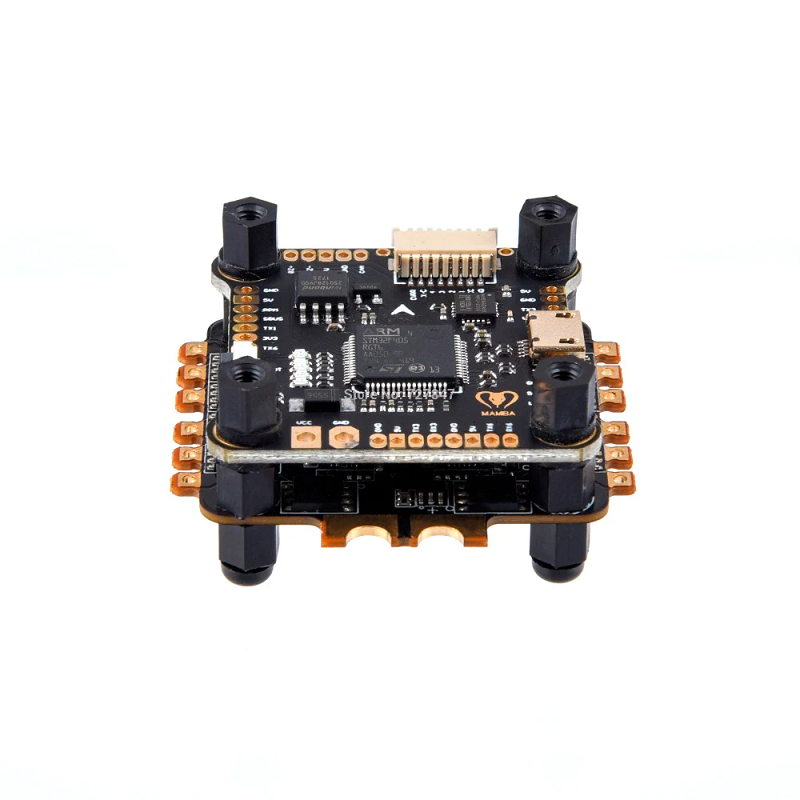
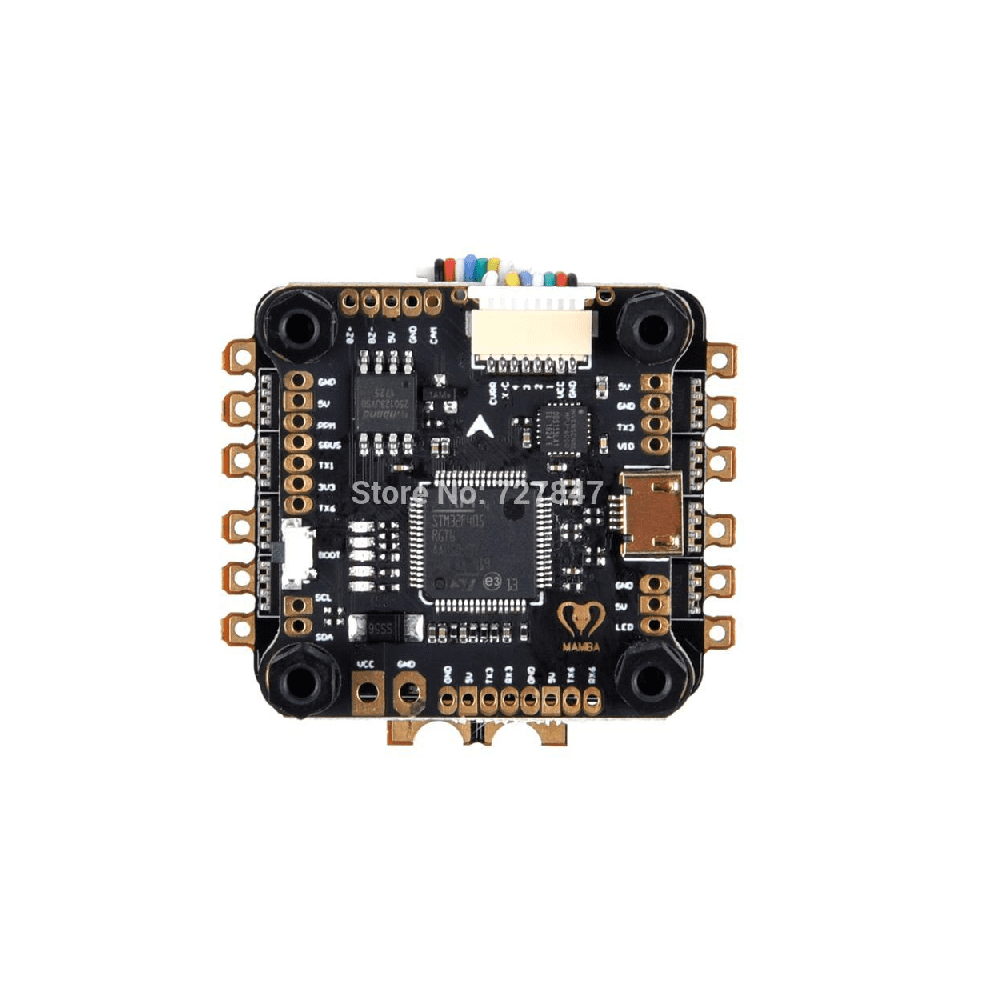
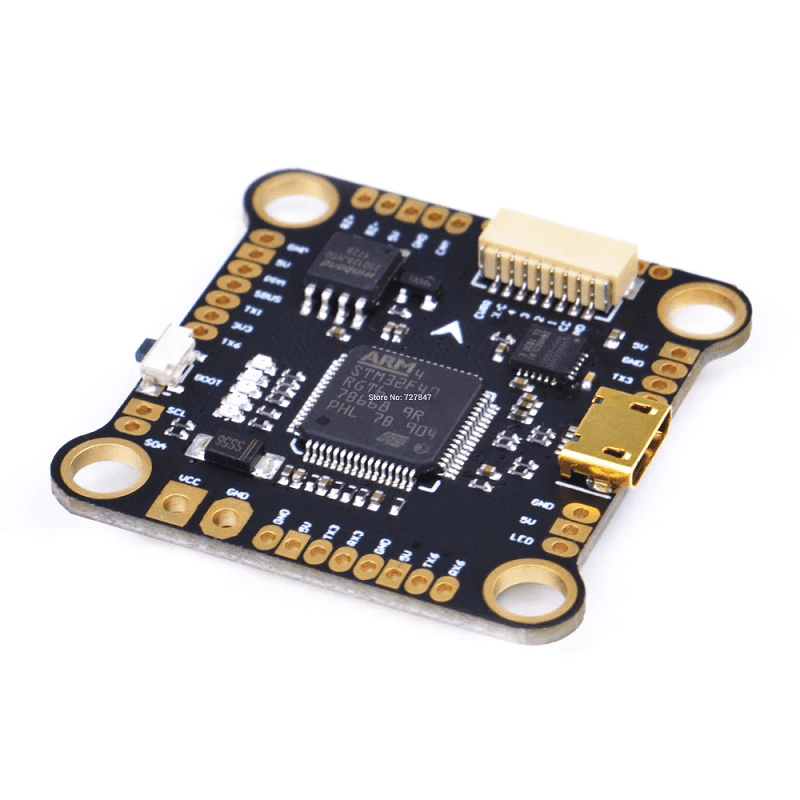
The Mamba F405 Flight Controller and REV35 35A 4-in-1 ESC Stack is an integrated flight-control and motor-speed-control assembly developed for compatible FPV racing drones and multirotor UAV platforms. It combines an STM32F405-based flight controller with a four-channel REV35 electronic speed controller, bringing aircraft stabilization, receiver-control processing and brushless motor-speed control together in a compact stack configuration.
The flight-controller section incorporates an MPU6000 gyroscope, 16MB flash memory, a built-in current sensor and a 5V 1.5A BEC. The REV35 ESC uses a 48MHz BB21 microcontroller running BLHeli_S J_H_xx firmware and supports DShot600, PWM, OneShot and MultiShot control protocols. The combined assembly is specified for 2–6S LiPo battery systems and provides four ESC channels for compatible brushless multirotor propulsion.
The ESC is rated at 35A continuous current and 40A peak current per channel. A 30.5 × 30.5mm M3 mounting pattern supports installation in compatible FPV frames. By integrating the flight controller and 4-in-1 ESC, the stack simplifies component arrangement and reduces the wiring required compared with installing four separate ESC units.
Key Features
- Integrated F405 Flight Controller and 4-in-1 ESC: Combines the flight-control board and four motor-control channels in a coordinated stack assembly.
- STM32F405 Flight-Control MCU: Provides the main processing platform for compatible flight-control firmware and sensor-data processing.
- MPU6000 Gyroscope: Provides angular-motion measurements for flight-control algorithms and aircraft stabilization.
- REV35 Four-Channel ESC: Integrates four electronic speed controller channels for compatible brushless motor systems.
- 35A Continuous ESC Rating: Each ESC channel has a specified continuous current rating of 35A.
- 40A Peak ESC Rating: Each ESC channel has a specified peak current rating of 40A.
- 2–6S LiPo Compatibility: Supports compatible battery configurations from 2S to 6S.
- BB21 ESC Processor: Uses a 48MHz BB21 microcontroller for ESC operation.
- BLHeli_S Firmware: Runs BLHeli_S J_H_xx firmware on the ESC microcontroller.
- DShot600 Support: Supports DShot600 digital ESC control as the specified default protocol.
- Multiple ESC Signal Protocols: Also supports PWM, OneShot and MultiShot control protocols.
- Built-In Current Sensor: Incorporates current-monitoring functionality in the flight-controller system.
- 5V 1.5A BEC: Provides a regulated 5V output for compatible flight-controller peripherals and accessories.
- 16MB Flight-Controller Flash: Provides onboard flash memory for supported firmware and data functions.
- 30.5 × 30.5mm M3 Mounting Pattern: Supports mounting in compatible flight frames using the specified hole spacing.
- Integrated Stack Layout: Consolidates flight-control and ESC hardware to simplify installation and powertrain wiring.
Flight Controller Architecture & Processing
The flight-controller section is built around the STM32F405 microcontroller, which serves as the primary processing unit for compatible flight-control firmware. It processes inertial sensor information, receiver commands and configured control outputs for the aircraft.
The onboard MPU6000 gyroscope supplies angular-motion measurements used by compatible flight-control algorithms. These measurements contribute to aircraft attitude estimation and stabilization during multirotor operation.
The flight-controller section also incorporates 16MB of flash memory and a built-in current sensor. These features support the board’s firmware and power-monitoring functions. The exact flash-memory use and current-sensor calibration should be configured according to the installed firmware and hardware revision.
REV35 4-in-1 ESC & Brushless Motor Control
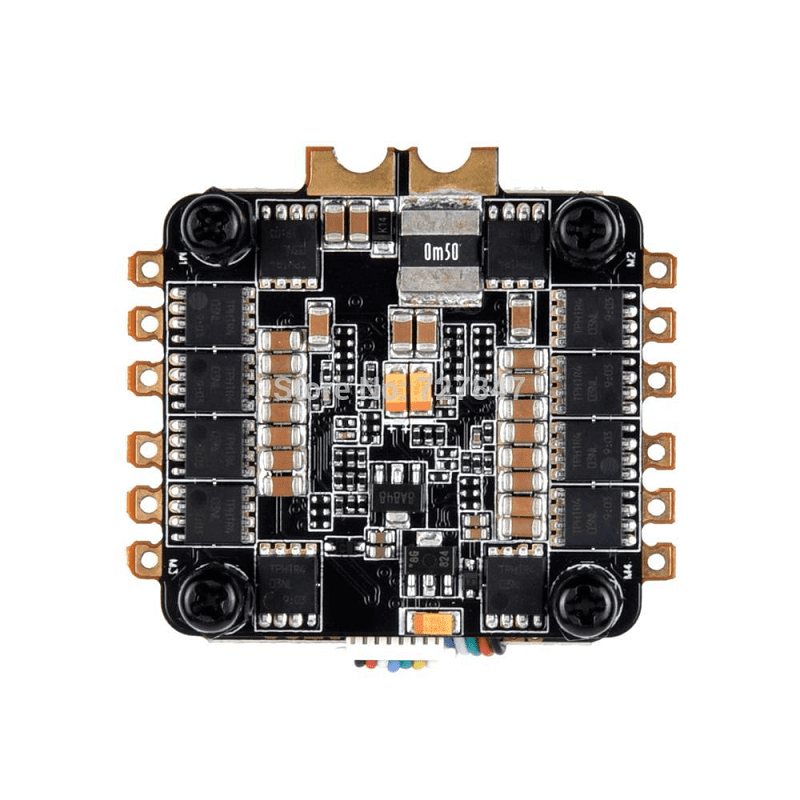
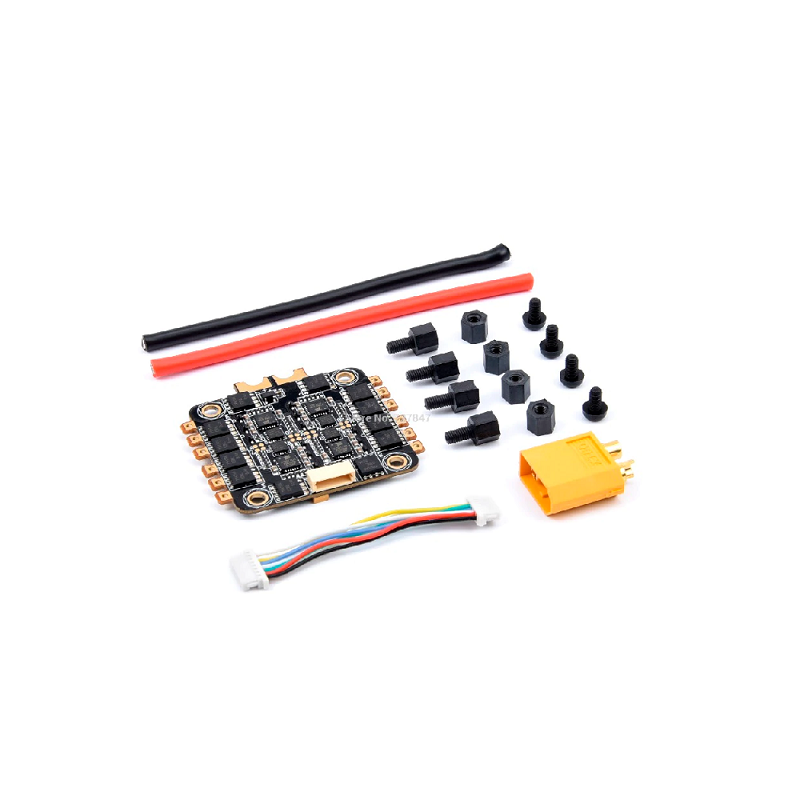
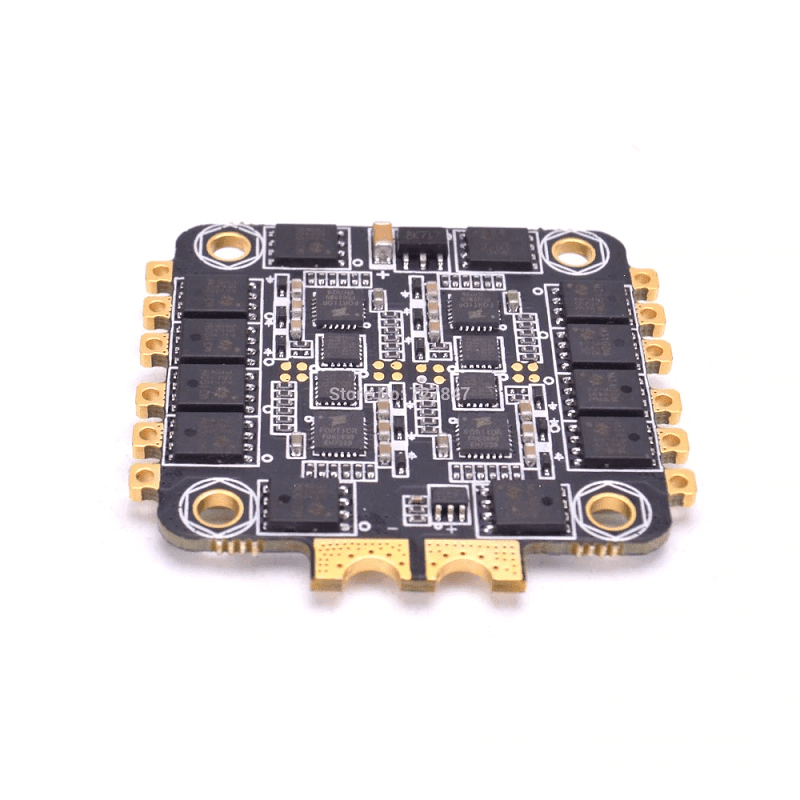
The REV35 4-in-1 Electronic Speed Controller integrates four ESC channels into a single board for controlling the brushless motors of a compatible multirotor aircraft. This arrangement consolidates motor-control electronics and simplifies the powertrain installation compared with using four individual ESC modules.
The ESC uses a BB21 microcontroller operating at 48MHz and runs BLHeli_S J_H_xx firmware. Its supported motor-control protocols include DShot600, PWM, OneShot and MultiShot, allowing configuration with compatible flight-controller firmware and signal outputs.
- Four ESC Channels: Provides four motor-control channels for compatible four-motor multirotor configurations.
- Continuous Current: 35A specified continuous rating per ESC channel.
- Peak Current: 40A specified peak rating per ESC channel.
- ESC Processor: BB21 MCU with a 48MHz operating frequency.
- ESC Firmware: BLHeli_S J_H_xx.
- Control Protocols: DShot600, PWM, OneShot and MultiShot.
Actual current capability depends on motor load, airflow, installation, battery conditions and ESC temperature. The peak rating should not be treated as a continuous operating rating.
Battery Input & Power Distribution
The stack is specified for 2S to 6S LiPo battery systems. The product specification identifies an input-power range of 12.6–25V for the stack, while the feature information describes 2–6S LiPo compatibility. Confirm the exact battery-input requirements and permitted voltage range for the supplied hardware revision before connecting a battery.
The flight-controller section incorporates a 5V 1.5A BEC to provide regulated low-voltage power for compatible peripherals. The combined load of the flight controller, receiver and connected accessories must remain within the regulator’s output capacity. Do not assume that every peripheral can be powered from this BEC simultaneously without checking its current requirements.
Current Monitoring & Power-System Integration
The built-in current sensor provides current-monitoring functionality for the flight-control system. When supported by the installed firmware, appropriate sensor configuration allows the flight controller to use current data as part of its power-monitoring and telemetry functions.
For reliable readings, configure the current-sensor scale and offset according to the board’s hardware characteristics and verify the displayed measurements against a suitable reference. The supplied specifications do not provide a current-sensor measurement range or calibration value.
Mounting & Stack Integration
The assembly uses a 30.5 × 30.5mm mounting-hole pattern with M3 mounting hardware, supporting installation in compatible FPV drone frames. Its integrated flight-controller and 4-in-1 ESC arrangement helps consolidate electronics around the aircraft’s central mounting area.
The combined stack is intended to simplify wiring between the flight-control and motor-control sections. Verify board orientation, mounting clearance, inter-board connections and motor-output assignments before final installation.
Applications
- FPV Racing Quadcopter Builds: Provides flight-control processing and four-channel motor-speed control for compatible racing drones.
- FPV Freestyle Drones: Supports multirotor builds requiring an integrated F405 flight controller and 4-in-1 ESC.
- Custom Quadcopter Development: Combines flight-control and propulsion electronics for compatible four-motor aircraft.
- 2S–6S LiPo Drone Platforms: Supports compatible multirotor power systems within the verified battery-input range.
- Brushless Motor Control: Provides four ESC channels for compatible brushless motors.
- DShot600-Based Systems: Supports digital ESC control with compatible flight-controller firmware.
- PWM ESC Configurations: Supports compatible motor-control systems using PWM signals.
- OneShot ESC Systems: Supports compatible OneShot motor-control configurations.
- MultiShot ESC Systems: Supports compatible MultiShot motor-control configurations.
- Betaflight-Based Multirotors: Suitable for compatible flight-control builds using firmware configured for the F405 board.
- Compact FPV Electronics Assemblies: Consolidates flight-control and ESC hardware into a single stack arrangement.
- Current-Monitoring Drone Systems: Supports power-system monitoring through its built-in current-sensor function.
- Four-Motor UAV Prototypes: Provides integrated control electronics for compatible experimental multirotor platforms.
Package Includes
- 1 × Mamba F405 Flight Controller
- 1 × REV35 35A BLHeli_S 2–6S 4-in-1 ESC
Product Specifications
| Parameter | Specification |
|---|---|
| Product Type | Flight Controller and 4-in-1 ESC Stack |
| Flight Controller Model | Mamba F405 |
| ESC Model | REV35 |
| ESC Configuration | 4-in-1, Four Channels |
| Flight Controller MCU | STM32F405 |
| Gyroscope | MPU6000 |
| Flight Controller Flash Memory | 16MB |
| ESC MCU | BB21 |
| ESC MCU Frequency | 48MHz |
| ESC Firmware | BLHeli_S J_H_xx |
| Battery Compatibility | 2–6S LiPo |
| Specified Input Power Range | 12.6–25V |
| ESC Continuous Current Rating | 35A per channel |
| ESC Peak Current Rating | 40A per channel |
| ESC Control Protocols | DShot600, PWM, OneShot and MultiShot |
| Default ESC Protocol | DShot600 |
| Flight Controller BEC | Integrated 5V, 1.5A |
| Current Sensor | Built-In |
| PWM Input | 4 PWM Inputs (as specified) |
| Mounting Hole Pattern | 30.5 × 30.5mm |
| Mounting Hardware Size | M3 |
| Assembly Length | 45mm |
| Assembly Width | 44mm |
| Assembly Height | 25mm |
Connection & Operating Recommendations
- Verify Battery Voltage: Confirm the battery-cell count and actual voltage range against the exact stack revision before connecting a LiPo battery. The supplied information specifies 2–6S compatibility and a 12.6–25V input range; verify this range against the board’s power-input documentation.
- Check Motor Connections: Connect each brushless motor to its designated ESC output and verify motor numbering and rotation direction through the flight-controller configuration software.
- Confirm ESC Protocol: Configure DShot600 or another supported protocol that is compatible with the installed flight-controller firmware and ESC firmware.
- Observe Current Ratings: Treat 35A as the continuous rating and 40A as the peak rating per channel. Motor load, airflow, battery condition and operating temperature affect actual ESC performance.
- Check BEC Load: Keep the total load on the 5V BEC within its 1.5A rating. Check the voltage and current requirements of receivers, cameras and other connected accessories.
- Configure Current Monitoring: Set the current-sensor parameters in compatible firmware and verify readings against a suitable reference before relying on telemetry values.
- Inspect Stack Wiring: Check inter-board connections, solder joints and power wiring for correct polarity, secure contact and accidental shorts before applying power.
- Use Suitable Cooling: Provide adequate airflow around the ESC during operation, particularly when operating at higher motor loads or sustained current levels.
- Verify Mounting Clearance: Confirm the 30.5 × 30.5mm M3 mounting pattern and check that screws, frame surfaces and other hardware do not contact exposed components or solder joints.
- Perform a Motor Test: Remove propellers before initial motor testing, verify motor order and direction, and check ESC response before flight.