SPIDER Automation ACEBOTT ESP32 Smart Car Starter Kit | 4WD Mecanum Drive & Multi-Interface Control | For Robotics & Embedded Programming
Description
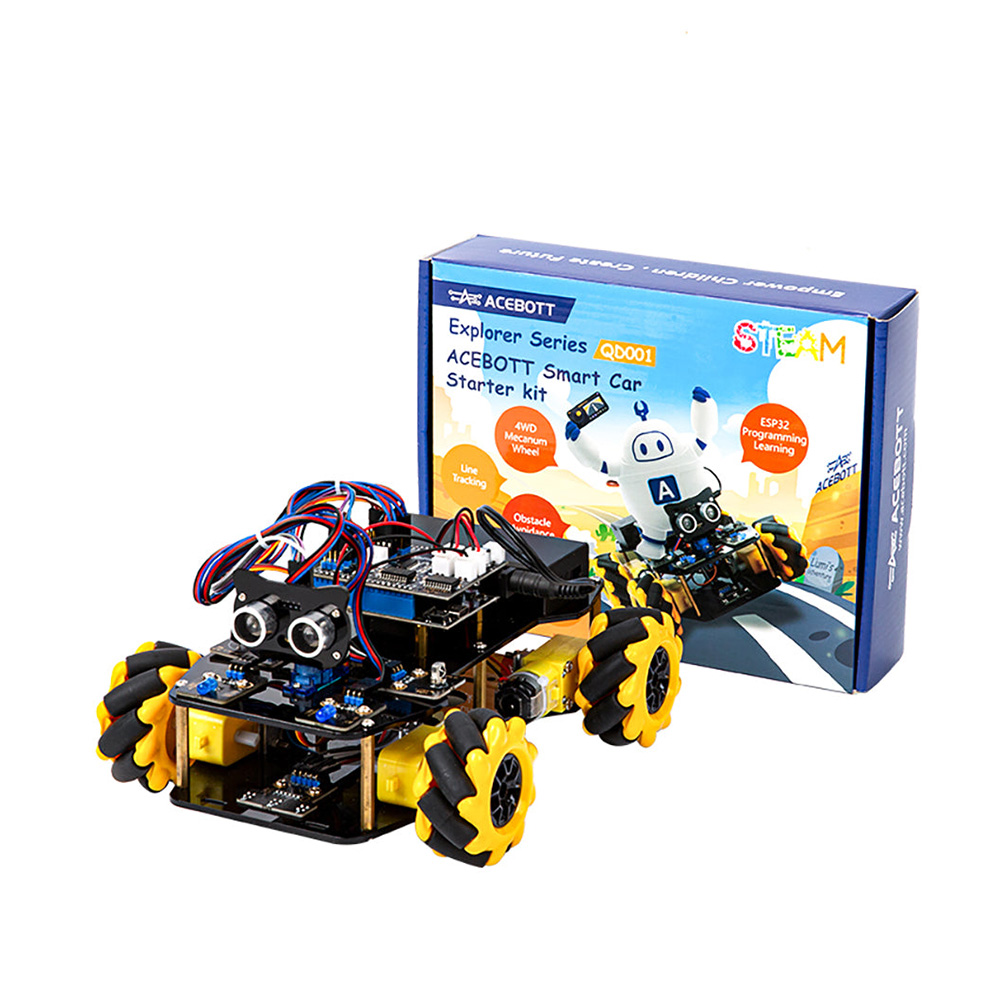
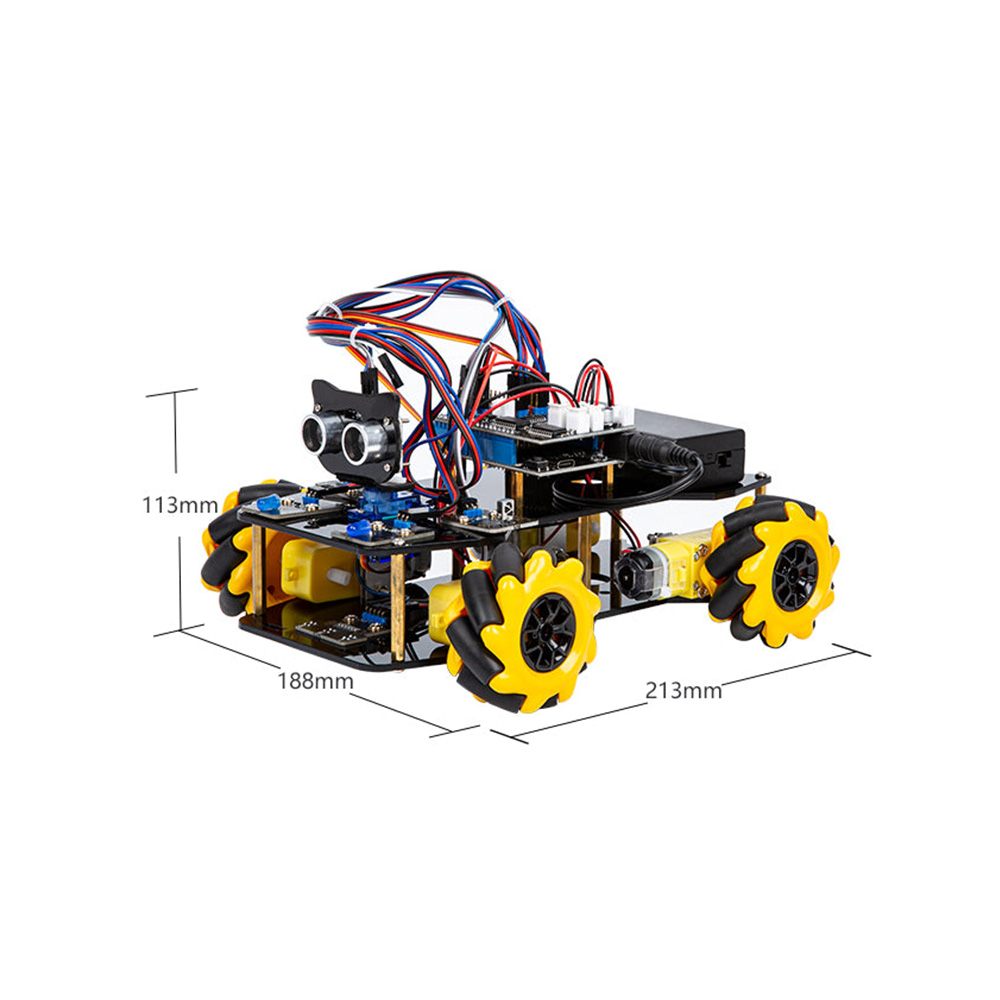
The ACEBOTT ESP32 Smart Car Starter Kit is a programmable robotic vehicle platform designed for hands-on learning in ESP32, Arduino programming, motor control and robotic navigation. The platform combines a four-wheel-drive Mecanum configuration with multiple control and interface options, providing a practical environment for developing and testing robotic movement and embedded control logic.
The 4WD Mecanum wheel system allows the vehicle to perform flexible multi-directional movement and multi-way cruising. Combined with obstacle-avoidance functionality, this provides a practical platform for exploring navigation logic, sensor integration and autonomous vehicle-control concepts.
The vehicle supports both infrared remote control and App-based control, giving users multiple methods for operating and testing the robotic platform. Its expandable architecture supports development from QD001 through QD007, allowing additional functions to be integrated as projects become more advanced.
With support for functions ranging from image-recognition integration to robotic-arm expansion, the platform can be extended beyond basic vehicle movement. A set of 16 tutorials provides a structured learning path for programming and robotics, while interfaces for analog reading, steering gear, line patrol, serial communication and ultrasonic functions provide multiple routes for experimentation.
Key Features
- ESP32-Controlled Platform: Provides the core programmable environment for embedded robotics projects.
- Arduino Programming: Suitable for learning and developing Arduino-based robotic control concepts.
- 4WD Mecanum Drive: Uses four driven Mecanum wheels for flexible vehicle movement.
- Multi-Directional Cruising: Supports movement in multiple directions using the Mecanum drive configuration.
- Obstacle Avoidance: Enables development of obstacle-detection and navigation functions.
- IR Remote Control: Provides infrared remote operation of the vehicle.
- App Control: Supports application-based wireless vehicle control.
- 16 Guided Tutorials: Provides structured programming and robotics learning activities.
- Expandable Architecture: Supports development options from QD001 to QD007.
- Image Recognition Expansion: The platform can be extended toward image-recognition-oriented projects.
- Robotic Arm Expansion: Supports development toward additional robotic mechanisms and functions.
- Analog Input Interface: Provides three-way analog reading capability for sensor-based projects.
- Steering Gear Interface: Provides three-way steering-gear connectivity.
- Line Patrol Interface: Supports line-following and tracking experiments.
- Serial Interface: Provides serial communication capability for connected modules and programming experiments.
- Ultrasonic Interface: Supports ultrasonic sensing and distance-related projects.
- L293D Motor Driver: Provides a 0.6A current limit with 1.2A peak current capability.
- Wide Supply Range: Supports 4.5–12V input according to the specified product data.
Benefits
- Structured Robotics Learning: Sixteen tutorials provide a guided route from basic programming toward more advanced vehicle functions.
- Practical Motor Control: The 4WD Mecanum configuration provides a physical platform for testing movement algorithms.
- Multiple Control Methods: IR remote and App control allow different approaches to vehicle operation.
- Expandable Platform: QD001–QD007 expansion options support progressively more capable projects.
- Sensor Integration: Analog, ultrasonic and line-patrol interfaces provide practical sensor-interaction opportunities.
- Embedded Development Practice: Combines software logic, motor control, navigation and hardware interfaces in one platform.
Applications
- Robotics Education: Practical programming and robotic vehicle-control training.
- ESP32 Development: Hands-on embedded programming and hardware-interface experiments.
- Arduino Projects: Vehicle-control and sensor-integration development using Arduino programming concepts.
- Autonomous Navigation: Obstacle avoidance, ultrasonic sensing and line-patrol projects.
- Remote-Controlled Robotics: IR and App-based robotic vehicle operation.
- Mecanum Drive Experiments: Development and testing of multi-directional movement algorithms.
- Computer Vision Projects: Expansion toward image-recognition-based robotic applications.
- Robotic Mechanism Development: Platform expansion using additional functions such as robotic arms.
Package Includes
- 1 × ACEBOTT Smart Car Starter Kit
Technical Specifications
| Parameter | Specification |
|---|---|
| Product Type | Car Kit / Programmable Smart Car |
| Controller Platform | ESP32 |
| Programming Platform | ESP32 / Arduino |
| Drive Configuration | 4WD Mecanum Wheel |
| Power Supply | 4.5–12V |
| Motor Driver | L293D |
| Current Limit | 0.6A |
| Peak Current | 1.2A |
| Control Methods | Infrared Remote, App Control |
| Navigation Functions | Multi-Way Cruising, Obstacle Avoidance |
| Expansion Range | QD001–QD007 |
| Analog Interface | 3-Way Analog Reading |
| Steering Gear Interface | 3-Way Steering Gear |
| Line Patrol Interface | Supported |
| Serial Interface | Supported |
| Ultrasonic Interface | Supported |
| Tutorials | 16 Tutorials |