
SPIDER Automation | A2212 10T 1400KV Brushless Motor | 16A Current Handling, 80% Efficiency & 2S–3S LiPo Propulsion
Description
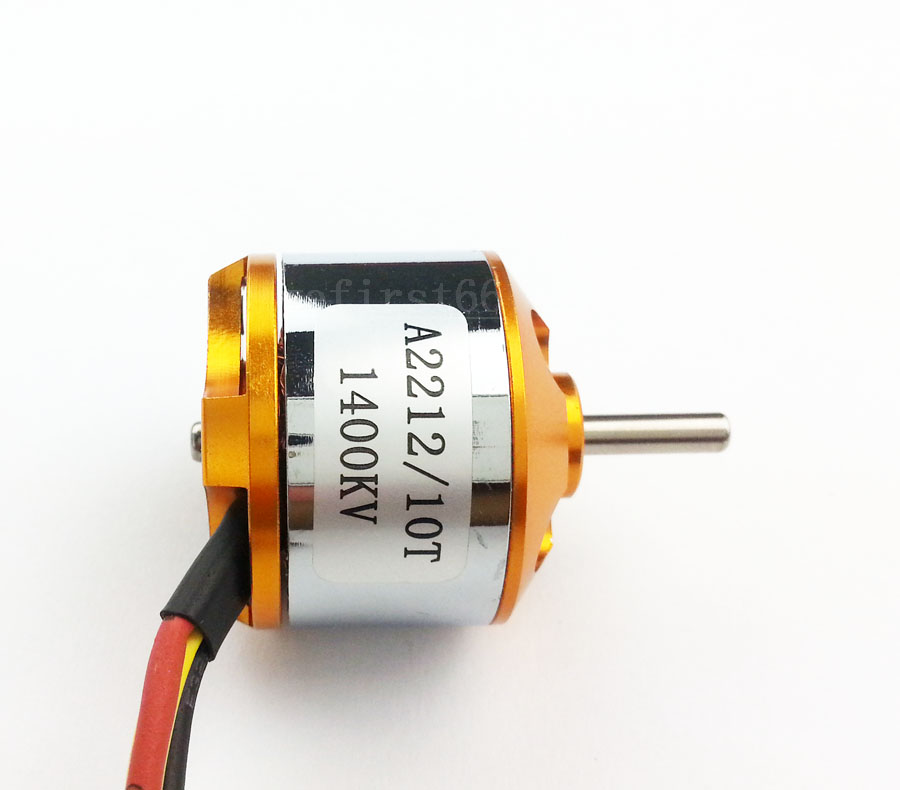
The A2212 10T 1400KV Brushless DC Outrunner Motor is designed for multirotor propulsion systems and compatible RC aircraft. Its 1400KV speed constant supports propulsion configurations operating with 2S–3S LiPo batteries. The motor has a specified current-handling capacity of 16A, a maximum-efficiency current range of 6–12A, a no-load current of 700mA and a listed maximum efficiency of 80%.
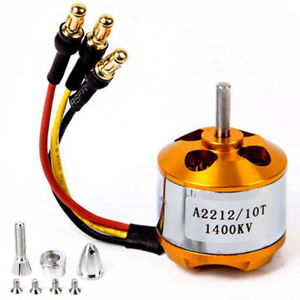
The motor features a solid metal housing, a 3.17mm output shaft and a pre-soldered connector for connection to a compatible brushless ESC. Its compact A2212 construction supports integration into compatible quadcopter, hexacopter and RC aircraft platforms. A SimonK 30A ESC and 1045 propeller are identified as a commonly used configuration, but the actual ESC and propeller suitability must be verified against the motor’s current and power requirements.
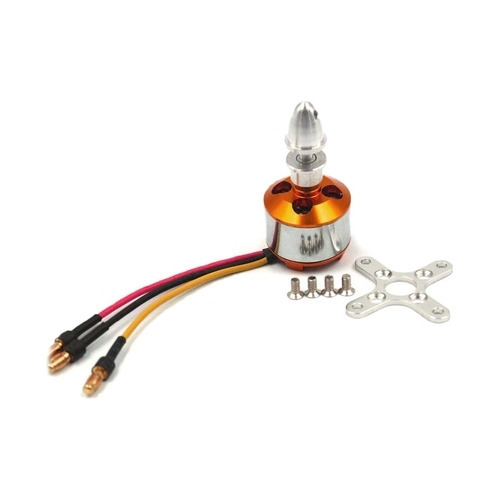
The package includes one A2212 10T 1400KV motor, one propeller adapter, one X-type motor holder and a set of mounting screws. Motor rotation can be configured for clockwise or counter-clockwise operation through appropriate three-phase motor wiring and ESC configuration.
A2212 10T Brushless Motor Design & Construction
The A2212 10T motor uses a compact brushless outrunner construction for electrically controlled multirotor propulsion. Its metal housing provides the external mechanical structure, while the pre-soldered connector simplifies integration with a compatible electronic speed controller.
- A2212 Motor Format: Compact brushless outrunner construction for compatible multirotor applications.
- 10T Winding Designation: Identified as the 10T motor variant.
- 1400KV Rating: Nominal speed constant of 1400 RPM per volt under no-load reference conditions.
- Brushless Operation: Electronic commutation through a compatible three-phase ESC.
- Solid Metal Housing: Metal outer construction provides mechanical support and protection.
- Compact Form Factor: Suitable for integration into compatible multirotor frames and RC aircraft.
Electrical Characteristics & Motor Efficiency
The motor is specified for 2S–3S LiPo battery configurations, with a current-handling capacity of 16A. Its maximum-efficiency current range is 6–12A, while the no-load current is listed as 700mA. Maximum efficiency is specified as 80%. These parameters are useful for preliminary propulsion-system selection, but actual current draw and efficiency depend on battery voltage, propeller loading, ESC operation and motor temperature.
- Motor KV: 1400KV.
- Current-Handling Capacity: 16A, as listed.
- Maximum-Efficiency Current: 6–12A.
- No-Load Current: 700mA.
- Maximum Efficiency: 80%.
- Battery Chemistry: LiPo.
- Battery Configuration: 2S–3S.
- Propeller Load Matching: Select a propeller that keeps motor current within verified operating limits.
Motor Connector & ESC Integration
The motor is supplied with a pre-soldered connector intended for connection to a compatible brushless ESC. A SimonK 30A ESC is identified as a commonly used pairing for this motor. The ESC must support the selected battery voltage, and its current capacity should be assessed against actual motor current under the intended propeller load.
- Motor Connector: Pre-soldered connector supplied.
- ESC Compatibility: Compatible brushless ESC required.
- Common ESC Configuration: SimonK 30A ESC identified as a commonly used pairing.
- Throttle Control: Motor speed is controlled electronically through the ESC.
- Electrical Matching: Verify connector fit, polarity and ESC battery-voltage compatibility before connection.
- Current Verification: Measure operating current with the selected propeller rather than relying only on the ESC model rating.
Shaft Interface & Mechanical Mounting
The A2212 motor has a 3.17mm output shaft for compatible propeller mounting hardware. The package includes a propeller adapter and an X-type motor holder with mounting screws. Before installation, confirm that the adapter matches the shaft and propeller hub, and that the motor holder aligns with the aircraft frame’s mounting arrangement.
- Output Shaft Diameter: 3.17mm.
- Propeller Adapter: One adapter included.
- Motor Holder: X-type cross holder.
- Mounting Hardware: One set of screws included.
- Motor Length: 27.5mm.
- Motor Weight: 27.5g, as listed.
- Mechanical Compatibility: Verify mounting-hole spacing, thread size and screw engagement before installation.
Rotation Direction & Propeller Configuration
The brushless motor can be configured for clockwise or counter-clockwise rotation through the three-phase connections between the motor and ESC. Rotation direction is controlled by the ESC’s phase sequence and supported configuration; reversing the battery input polarity is not the correct method. Propeller orientation must match the configured motor rotation direction.
- Rotation Capability: CW or CCW through appropriate ESC-controlled phase configuration.
- Phase Connection: Swapping any two of the three motor phase connections reverses rotation on a conventional brushless ESC.
- Propeller Matching: Use a propeller designed for the selected rotation direction.
- System Verification: Check motor direction before installing propellers and performing flight tests.
Applications
The A2212 10T 1400KV motor is suitable for compatible brushless propulsion assemblies where its 2S–3S voltage range, current-handling capacity, shaft interface and mounting configuration meet the aircraft’s requirements.
- Quadcopter Propulsion: Motor integration in compatible four-motor aircraft platforms.
- Hexacopter Propulsion: Use in compatible six-motor configurations after evaluating total power requirements.
- Multirotor Aircraft: Brushless propulsion for compatible multi-motor aerial platforms.
- RC Airplanes: Propulsion integration in compatible fixed-wing radio-controlled aircraft.
- UAV Development: Motor integration for compatible unmanned aerial vehicle designs.
- 2S LiPo Propulsion Systems: Use in compatible aircraft designed around two-cell LiPo power.
- 3S LiPo Propulsion Systems: Use in compatible aircraft designed around three-cell LiPo power.
- 1045 Propeller Configurations: Can be evaluated with compatible 1045 propellers after checking current draw and propulsion performance.
- Q450-Style Multirotor Frames: Potential integration where motor mounting and propeller requirements match.
- Flight-Control System Integration: Use with compatible flight controllers and brushless ESCs.
- UAV Propulsion Prototyping: Evaluation of motor, ESC, battery and propeller combinations.
- Brushless Motor Performance Testing: Controlled measurement of current draw, speed, thrust and operating temperature.
- Motor Replacement: Replacement of compatible A2212-format motors after checking winding variant, shaft and mounting interfaces.
- Aerial Photography Platforms: Propulsion integration in suitable camera-carrying multirotors.
- Engineering Test Platforms: Evaluation of brushless motor control and multirotor propulsion assemblies.
Package Includes
- 1 × A2212 10T 1400KV Brushless DC Outrunner Motor
- 1 × Propeller Adapter
- 1 × X-Type Motor Holder
- 1 Set Motor Holder Mounting Screws
Product Specifications
| Parameter | Specification |
|---|---|
| Product Type | Brushless DC Outrunner Motor |
| Motor Model | A2212 10T |
| Winding Designation | 10T |
| KV Rating | 1400KV |
| Nominal Speed Constant | 1400 RPM/V (no-load reference) |
| Current-Handling Capacity | 16A |
| Maximum-Efficiency Current | 6–12A |
| No-Load Current | 700mA |
| Maximum Efficiency | 80% |
| Battery Chemistry | LiPo |
| Compatible Battery Configuration | 2S–3S |
| Shaft Diameter | 3.17mm |
| Motor Housing | Solid metal construction |
| Motor Connector | Pre-soldered connector |
| Rotation Configuration | CW or CCW through appropriate ESC-controlled phase configuration |
| Common ESC Pairing | SimonK 30A brushless ESC, as a commonly used configuration |
| Common Propeller Configuration | 1045 propeller, subject to load and compatibility verification |
| Motor Length | 27.5mm |
| Motor Weight | 27.5g, as listed |
| Propeller Adapter | 1 included |
| Motor Holder | X-type cross holder |
| Mounting Hardware | One screw set included |
Connection & Operating Recommendations
- Verify Battery Voltage: Operate within the specified 2S–3S LiPo range and confirm that the ESC supports the selected battery configuration.
- Select a Suitable ESC: Choose an ESC with adequate continuous and peak current ratings for the measured motor load.
- Check Propeller Loading: Verify the actual current draw with the selected propeller before flight operation. The 1045 configuration is not a universal compatibility guarantee.
- Confirm Connector Compatibility: Check the supplied pre-soldered motor connector against the ESC connector before connection.
- Check Motor Rotation: Configure the required CW or CCW direction through the motor phase connections or supported ESC settings.
- Match Propeller Direction: Ensure the propeller orientation corresponds to the motor’s configured rotation.
- Secure the Propeller Adapter: Verify compatibility with the 3.17mm shaft and the selected propeller hub.
- Inspect Motor Mounting: Confirm that the X-type holder aligns with the frame and that mounting screws have suitable engagement.
- Monitor Current and Temperature: Check electrical load and motor temperature during controlled initial testing.
- Check Mechanical Vibration: Inspect propeller balance, shaft condition and motor mounting if abnormal vibration occurs.
- Perform Controlled Testing: Verify rotation and throttle response without a propeller before conducting controlled propeller-load testing.