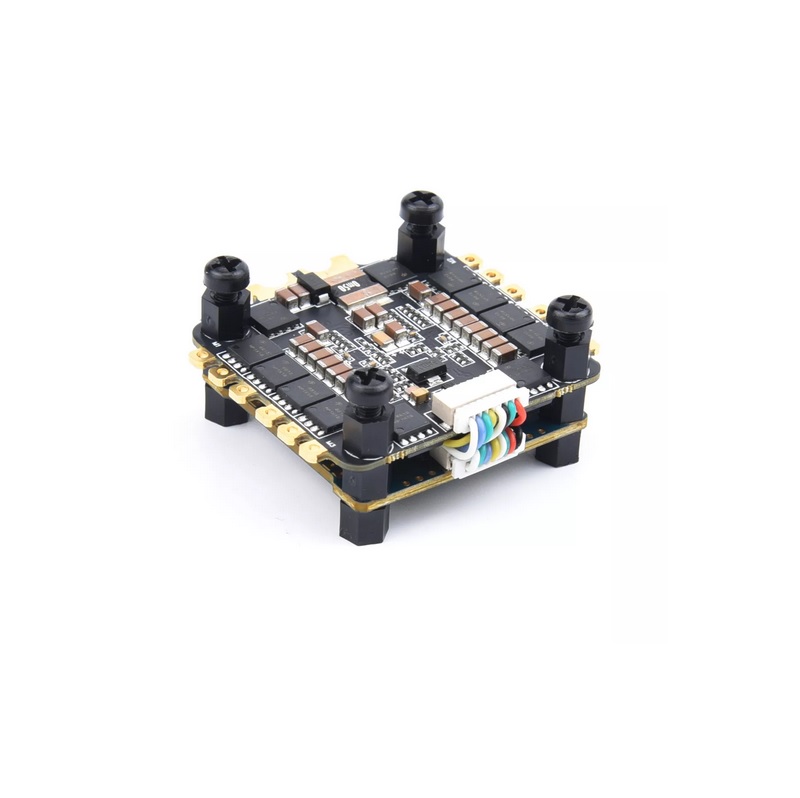

SPIDER Automation F4 V3 PLUS Flight Controller & REV35 35A 4-in-1 ESC Combo Stack | Integrated OSD, Blackbox & FPV Motor Control
Description
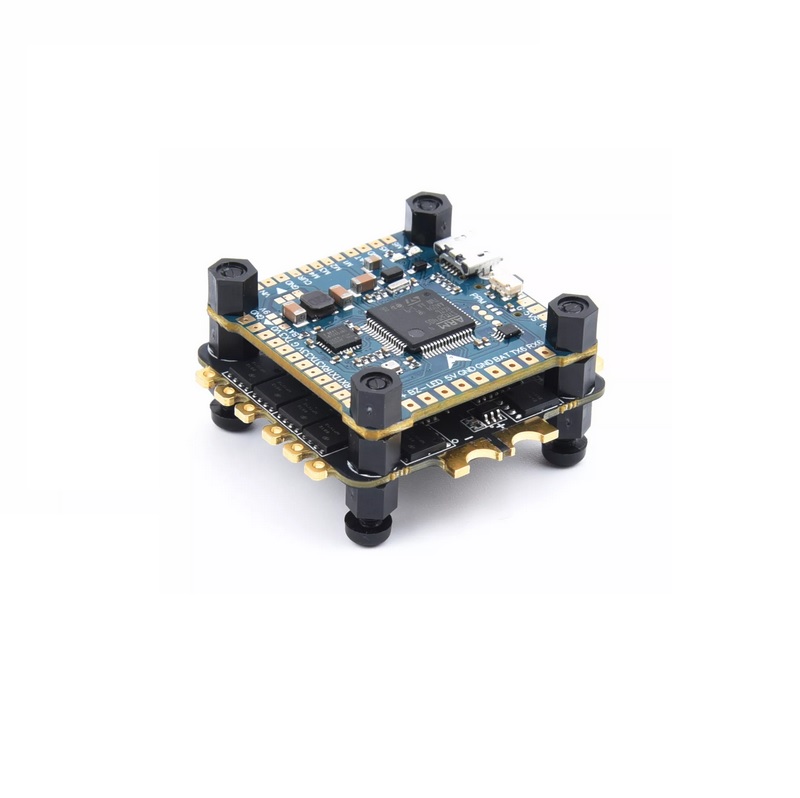
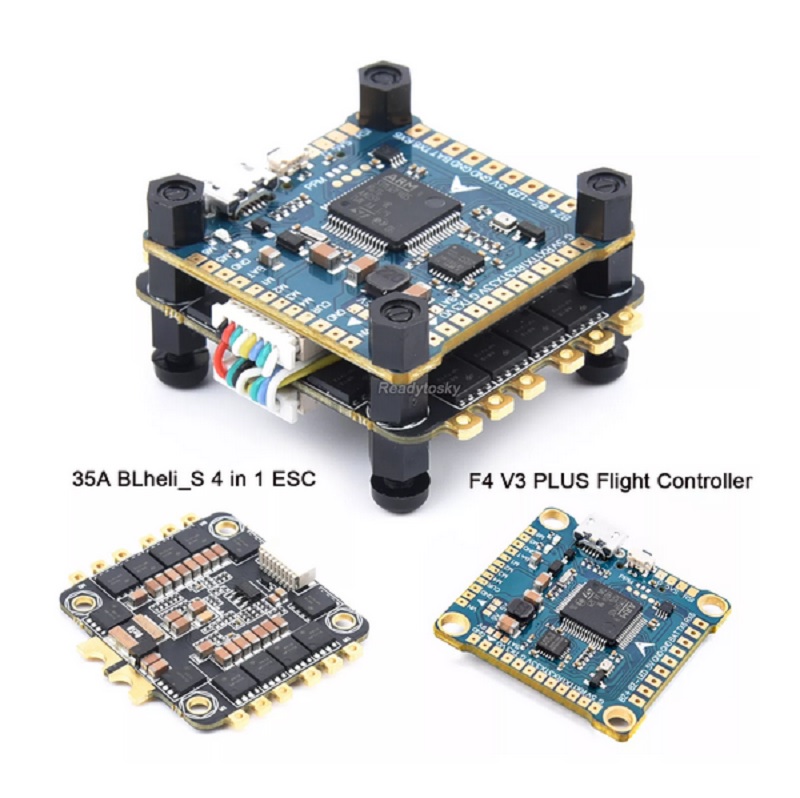
The F4 V3 PLUS Flight Controller and REV35 35A 4-in-1 ESC Combo Stack is an integrated flight-control and electronic speed controller assembly designed for compatible FPV racing drones, freestyle quadcopters and multirotor UAV platforms. It combines an STM32F405-based flight controller with a four-channel BLHeli_S ESC, providing the processing and motor-control functions required for a compatible brushless multirotor powertrain.
The F4 V3 PLUS flight controller incorporates a six-axis SPI inertial measurement unit, with BMI270 or MPU6500 sensor variants, along with a BMP280 barometer, integrated Betaflight OSD and MicroSD Blackbox functionality. Receiver interfaces include SBUS, PPM and Spektrum DSMX. The board also provides regulated 5V and 9V power outputs and onboard video filtering for the specified 5V camera and VTX supply connections.
The included REV35 35A 4-in-1 ESC uses a BB21 microcontroller operating at 48MHz and BLHeli_S J_H_xx firmware. It supports 3–6S LiPo battery configurations and DShot600, PWM, OneShot and MultiShot control protocols. With four integrated ESC channels and a 30.5 × 30.5mm flight-controller mounting pattern, this combo stack provides a consolidated electronics platform for compatible FPV multirotor builds.
Key Features
- F4 V3 PLUS Flight Controller: Integrates flight-control processing, inertial sensing, barometric sensing, OSD and flight-data logging functions.
- STM32F405 ARM MCU: Provides the main processing platform for compatible flight-control firmware and sensor-data handling.
- BMI270 / MPU6500 IMU Variants: Supports a six-axis SPI gyroscope and accelerometer configuration for aircraft motion measurement.
- BMP280 Barometer: Provides barometric pressure measurements for compatible altitude-related flight-control functions.
- Betaflight OSD: Supports drag-and-drop OSD configuration through Betaflight for FPV video telemetry display.
- MicroSD Blackbox: Provides onboard flight-data logging functionality using a compatible MicroSD card.
- REV35 4-in-1 ESC: Integrates four electronic speed controller channels for a four-motor brushless propulsion system.
- 35A ESC Current Rating: Provides a specified 35A rating per ESC channel.
- 3–6S LiPo ESC Compatibility: Supports compatible 3S, 4S, 5S and 6S LiPo battery configurations.
- BB21 ESC Microcontroller: Uses a 48MHz processor running BLHeli_S J_H_xx firmware.
- DShot600 Support: Supports digital ESC control using DShot600 with compatible flight-controller firmware.
- Additional ESC Protocols: Supports PWM, OneShot and MultiShot motor-control protocols.
- Multiple Receiver Interfaces: Supports SBUS, PPM and Spektrum DSMX receiver connections.
- Dual BEC Voltage Outputs: Provides 5V and 9V regulated power outputs for compatible peripherals.
- Onboard Video Filtering: Incorporates video-power filtering for the specified 5V camera and VTX supply connections.
- 30.5 × 30.5mm Mounting: Uses a standard mounting-hole pattern for compatible FPV frames.
Flight Controller Processing & Inertial Measurement
The F4 V3 PLUS flight controller is based on the STM32F405 ARM microcontroller, which processes flight-control inputs, sensor measurements and configured motor-control commands. Its processor works with the onboard inertial measurement unit to support aircraft attitude estimation and stabilization through compatible flight-control firmware.
The six-axis SPI IMU combines gyroscope and accelerometer functions. The board is supplied with either a BMI270 or MPU6500 sensor variant. These sensors measure angular motion and linear acceleration, providing data used by the flight controller’s stabilization and control algorithms.
The integrated BMP280 barometer provides atmospheric pressure measurements for compatible altitude-related flight-control functions. Its operation depends on sensor configuration, firmware support, installation and environmental conditions.
Integrated OSD & FPV Video System
The flight controller includes an integrated Betaflight On-Screen Display (OSD) for overlaying configured flight information onto the FPV video feed. Its drag-and-drop configuration workflow allows supported OSD elements to be arranged through Betaflight, helping configure the displayed telemetry according to the aircraft’s requirements.
The board also incorporates onboard video filtering for the specified 5V camera and VTX power connections. This filtering is intended to help manage electrical noise in the video-power supply path. The stated filtering provision applies to the specified 5V connections and should not be assumed to cover every possible peripheral supply arrangement.
MicroSD Blackbox Flight-Data Logging
The F4 V3 PLUS flight controller provides a MicroSD Blackbox interface for supported flight-data logging configurations. Blackbox recording can be used to capture flight-controller data for post-flight analysis, tuning and troubleshooting when the installed firmware and MicroSD card are configured appropriately.
Card compatibility, supported capacity, file-system requirements and logging performance depend on the board implementation and firmware configuration. Use a compatible MicroSD card and verify its operation through the installed Betaflight configuration before flight testing.
Receiver Connectivity & Flight-Control Integration
The flight controller supports SBUS, PPM and Spektrum DSMX receiver interfaces for integration with compatible radio-control systems. The selected receiver connection must match the receiver’s output protocol and the board’s corresponding input configuration.
During flight operation, the flight controller processes receiver commands together with inertial sensor measurements and configured control algorithms. It then generates motor-control signals for the ESC. This allows the controller and ESC to coordinate motor-speed changes required for aircraft manoeuvring and stabilization.
REV35 35A 4-in-1 ESC & Motor Control
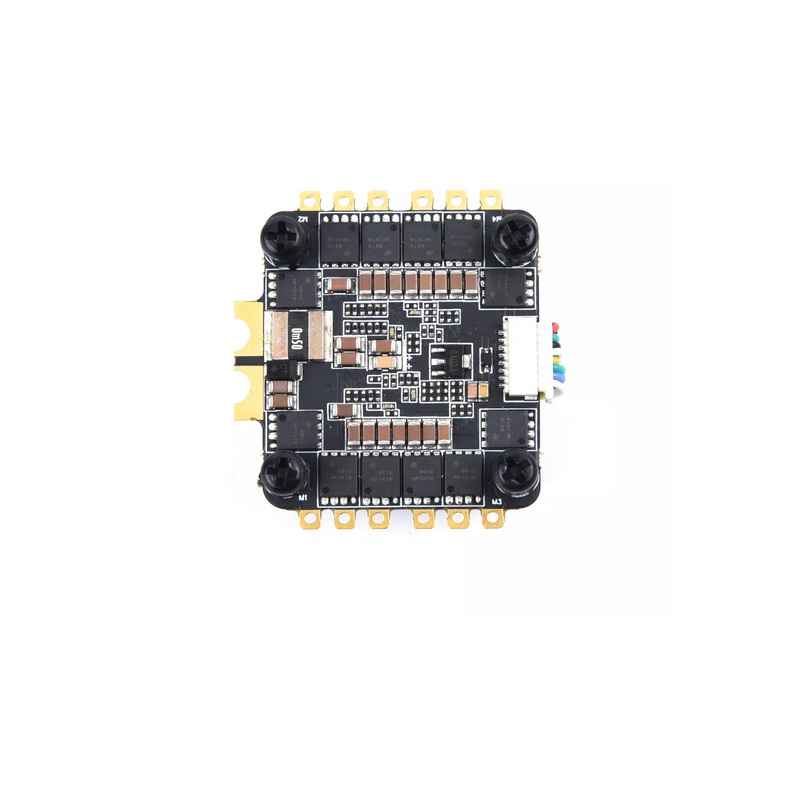
The included REV35 4-in-1 Electronic Speed Controller integrates four ESC channels into a single assembly for controlling four compatible brushless motors. Its integrated arrangement consolidates motor-control electronics and simplifies the powertrain layout compared with using four separate ESC boards.
The ESC uses a BB21 microcontroller operating at 48MHz and runs BLHeli_S J_H_xx firmware. Its supported control protocols include DShot600, PWM, OneShot and MultiShot, allowing integration with compatible flight-controller firmware and motor-output configurations.
- Four Motor Channels: Provides four ESC channels for compatible four-motor multirotor propulsion systems.
- Continuous Current Rating: 35A specified per ESC channel.
- ESC Firmware: BLHeli_S J_H_xx.
- ESC Processor: BB21 microcontroller with a 48MHz operating frequency.
- Digital Motor Control: Supports DShot600 with compatible flight-control configuration.
- Additional Signal Protocols: Supports PWM, OneShot and MultiShot.
Actual ESC current capability depends on motor load, airflow, installation, battery conditions and operating temperature. The 35A rating should be assessed alongside the motor manufacturer’s current requirements and the cooling available in the aircraft frame.
Power Management & BEC Outputs
The F4 V3 PLUS flight controller provides 5V and 9V BEC outputs for powering compatible flight-control peripherals and FPV equipment. These regulated outputs can be used for supported components when their operating voltage and current requirements match the relevant power rail.
The board specification identifies 5V 3A and 9V 3A outputs. The available current depends on the regulator design, input conditions, thermal limits and simultaneous loading. Check the board’s power-distribution documentation before assigning high-current accessories to either output.
The REV35 ESC is identified as having no onboard LBEC or SBEC. The flight controller’s BEC outputs should therefore be treated as flight-controller power outputs, not as evidence of a separate ESC auxiliary regulator.
Mechanical Design & Installation
The flight-controller board measures 36 × 36mm and uses a 30.5 × 30.5mm mounting-hole pattern. This mounting arrangement is used across many FPV drone frames and supports installation in compatible stack configurations.
The integrated flight-controller and 4-in-1 ESC arrangement helps organize flight-control electronics and motor-power connections within the central electronics area of the aircraft. Confirm board orientation, mounting clearance, connector alignment and wiring compatibility before installation.
Applications
- FPV Racing Quadcopters: Provides flight-control processing and four-channel motor control for compatible racing drone platforms.
- FPV Freestyle Drones: Supports freestyle multirotor builds requiring integrated F4 flight control and 4-in-1 ESC hardware.
- Custom Multirotor UAVs: Combines inertial sensing, flight-control processing and brushless motor-speed control.
- 3–6S FPV Drone Power Systems: Supports compatible multirotor ESC configurations using 3S to 6S LiPo batteries.
- Brushless Quadcopter Propulsion: Provides four ESC channels for compatible brushless motor installations.
- Betaflight-Based Aircraft: Supports compatible flight-control builds configured through Betaflight.
- DShot600 Motor-Control Systems: Supports digital ESC signalling for compatible flight-controller configurations.
- PWM Motor-Control Systems: Supports compatible ESC configurations using PWM control signals.
- OneShot-Based ESC Systems: Supports compatible motor-control setups using OneShot protocols.
- MultiShot-Based ESC Systems: Supports compatible motor-control setups using MultiShot protocols.
- FPV Video Telemetry Systems: Uses integrated OSD functionality to display configured flight information in the video feed.
- Flight-Data Analysis: Supports MicroSD Blackbox logging for compatible firmware-based tuning and troubleshooting workflows.
- Barometer-Assisted Flight Systems: Provides BMP280 pressure measurements for supported altitude-related flight-control functions.
- Receiver-Integrated RC Platforms: Supports compatible SBUS, PPM and Spektrum DSMX radio receiver interfaces.
- Compact FPV Electronics Assemblies: Combines flight-control and ESC hardware in a consolidated stack arrangement.
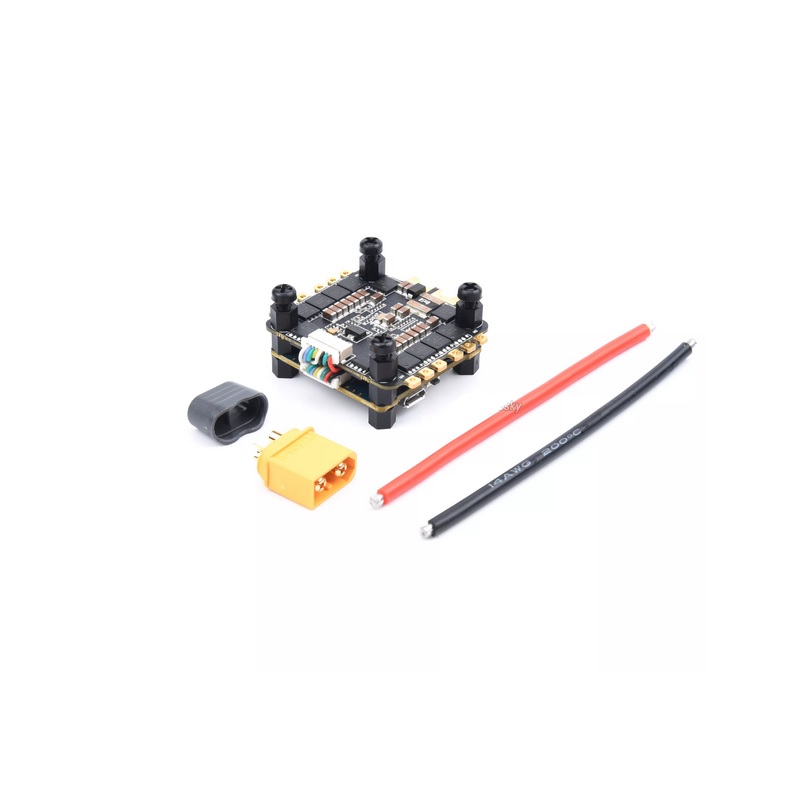
Package Includes
- 1 × F4 V3 PLUS Flight Controller
- 1 × REV35 35A BLHeli_S 4-in-1 ESC
Product Specifications
| Parameter | Specification |
|---|---|
| Product Type | Flight Controller and 4-in-1 ESC Combo Stack |
| Flight Controller Model | F4 V3 PLUS |
| ESC Model | REV35 |
| Flight Controller MCU | STM32F405 ARM Processor |
| IMU Configuration | 6-Axis SPI Gyroscope and Accelerometer |
| IMU Sensor Variants | BMI270 or MPU6500 |
| Barometer | BMP280 |
| OSD | Integrated Betaflight OSD with drag-and-drop configuration |
| Blackbox | MicroSD-Based Flight-Data Logging |
| Receiver Protocols | SBUS, PPM and Spektrum DSMX |
| ESC Configuration | 4-in-1, Four Channels |
| ESC Continuous Current Rating | 35A |
| ESC Battery Compatibility | 3–6S LiPo |
| ESC MCU | BB21 |
| ESC MCU Frequency | 48MHz |
| ESC Firmware | BLHeli_S J_H_xx |
| ESC Control Protocols | DShot600, PWM, OneShot and MultiShot |
| Default ESC Protocol | DShot600 |
| 5V BEC Output | 3A |
| 9V BEC Output | 3A |
| Onboard Video Filtering | Provided for specified 5V camera and VTX power connections |
| ESC LBEC | No |
| ESC SBEC | No |
| Flight Controller Board Size | 36 × 36mm |
| Mounting Hole Pattern | 30.5 × 30.5mm |
Connection & Operating Recommendations
- Confirm the IMU Variant: Check whether the supplied flight-controller revision uses the BMI270 or MPU6500 sensor and select the matching firmware target and sensor configuration.
- Verify ESC Battery Compatibility: The REV35 ESC is specified for 3–6S LiPo operation. Confirm the battery-cell count and the complete stack’s power-input requirements before connecting the battery.
- Check Power-Rail Requirements: Connect peripherals to the appropriate 5V or 9V output only after confirming their permitted input voltage and current consumption.
- Respect BEC Current Limits: Account for the combined load of all devices connected to each BEC output. Confirm regulator ratings and thermal limitations in the board documentation.
- Match Receiver Protocol: Configure the flight controller for the connected SBUS, PPM or Spektrum DSMX receiver interface.
- Configure the ESC Protocol: Select DShot600, PWM, OneShot or MultiShot according to the installed firmware and the ESC configuration.
- Configure OSD and Blackbox: Set up the OSD through Betaflight and verify MicroSD card recognition and Blackbox recording before flight.
- Check Video Connections: Use the specified 5V filtered supply connections for compatible camera and VTX equipment. Verify polarity and voltage before connecting video components.
- Verify Motor Outputs: Check motor numbering, wiring and rotation direction using the flight-controller configuration software before fitting propellers.
- Inspect Mounting and Wiring: Confirm the 30.5 × 30.5mm mounting pattern, board orientation, connector clearance and secure electrical connections.
- Test Without Propellers: Perform initial receiver, motor, OSD and power-system checks with all propellers removed.