
SPIDER Automation | ZTW Spider Series 60A OPTO Brushless ESC | SimonK OneShot125 Speed Controller
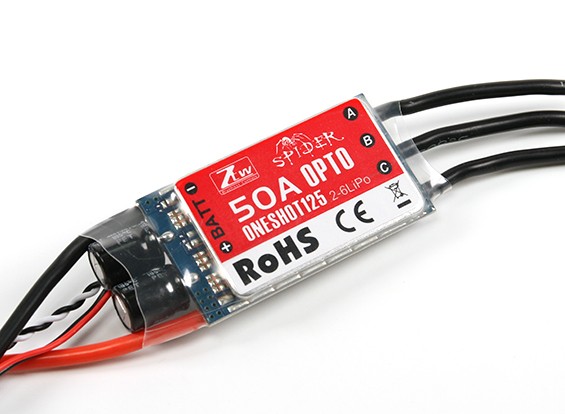
The ZTW Spider Series 60A OPTO Brushless ESC (Model: ZTW-SPIDER-60A) is an industrial-grade electronic speed controller engineered specifically for multi-rotor aircraft, heavy-lift hexacopters, and high-performance FPV platforms. Multi-rotor flight stability relies on instantaneous, precise motor speed adjustments managed by the flight controller. Standard general-purpose ESC firmware often introduces throttle latency and non-linear response curves that degrade flight control loop performance. The ZTW Spider series solves this by integrating high-performance microcontrollers (MCUs) pre-flashed with factory-optimized SimonK OneShot125 firmware, ensuring ultra-fast command execution and silky-smooth throttle linearity.
Designed to operate across a wide input voltage span from 7.4V to 22.2V DC (2S to 6S LiPo battery packs), the ZTW-SPIDER-60A delivers up to 60 Amperes of burst current. It features an OPTO-isolated architecture that completely separates high-current motor circuits from sensitive receiver signal lines, paired with a specialized 12V auxiliary power output for driving onboard peripherals like FPV video transmitters or auxiliary LEDs. Encased in a robust 55 × 30 × 13 mm housing weighing 48 grams, this ESC incorporates thermal overload protection, signal loss auto-shutdown, and secure throttle stick programming capabilities for uncompromised operational reliability.
Product Overview & Functional Design
The ZTW Spider 60A ESC power management system is built for drone technicians, commercial UAV integrators, and advanced robotics engineers who demand high reliability under severe operating loads. High-KV brushless motors drawing heavy currents generate intense thermal and electromagnetic stress; the low internal resistance (Low-IR) MOSFETs utilized in this ESC minimize resistive heat generation and voltage sag.
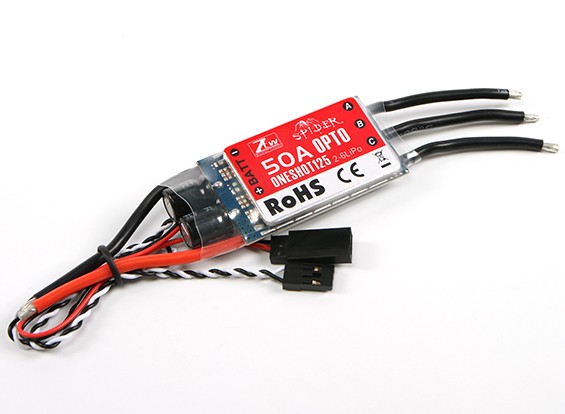
The inclusion of a standard JR-type servo signal lead ensures seamless plug-and-play compatibility with open-source and proprietary flight controllers such as Pixhawk, APM, Betaflight, and standard multi-channel RC receivers. Note that battery and motor bullet connectors are uninstalled, allowing builders to customize wire lengths and solder high-current connections directly to their power distribution architecture.
Technical Features & Functional Characteristics
- Optimized SimonK OneShot125 Firmware: Pre-flashed at the factory for ultra-fast PWM refresh rates and zero-lag throttle response.
- 60A Burst Current Capability: Robust power handling designed to withstand extreme electrical surges during high-G acrobatic maneuvers.
- Wide 2S to 6S LiPo Support: Universal voltage compatibility spanning 7.4V to 22.2V DC multi-cell lithium power banks.
- OPTO Isolated Signal Circuit: Eliminates ground loops and electromagnetic interference (EMI) between motor power buses and flight receivers.
- Dedicated 12V Auxiliary Output: Provides a stable 12V power tap for driving FPV cameras, video transmitters, and auxiliary equipment.
- Thermal Overload Protection: Built-in temperature monitoring safeguards internal circuitry against catastrophic thermal runaway.
- Signal Loss Auto-Throttle Shutdown: Instantly cuts motor PWM output if radio transmitter signal or flight controller telemetry is lost.
- Safe-Start Arming Interlock: Prevents motor startup unless the throttle stick is verified at zero position during system boot.
- Low Internal Resistance MOSFETs: High-efficiency semiconductor layout minimizes electrical power loss and heat dissipation.
- Throttle Stick Programmable: Supports custom parameter calibration directly via transmitter throttle stick inputs.
Firmware Performance & Throttle Linearity
The integration of SimonK firmware with OneShot125 protocol support transforms how brushless motors interact with flight stabilization loops. Traditional ESCs process standard 50Hz–400Hz PWM signals, introducing a measurable delay between flight controller corrective commands and physical motor RPM changes. OneShot125 shortens the control pulse duration significantly, allowing the flight computer to stream throttle updates directly to the ESC at speeds up to eight times faster.
This ultra-low latency results in locked-in multi-rotor stability, crisp PID loop execution, and buttery-smooth throttle linearity across the entire RPM spectrum, eliminating micro-stutter and oscillation during aggressive flight maneuvers.
System Compatibility & Hardware Integration
The ZTW-SPIDER-60A ESC is compatible with a broad range of multi-rotor motors, power systems, and flight control platforms:
- Brushless Outrunner & Inrunner Motors: Pairs perfectly with high-power multi-rotor and fixed-wing brushless motors requiring high current handling.
- Multi-Rotor Flight Controllers: Compatible with Pixhawk, Betaflight, INAV, and APM flight management boards supporting PWM/OneShot outputs.
- RC Radio Control Systems: Interfaces with 2.4GHz receivers from FrSky, FlySky, Futaba, Spektrum, and TBS Crossfire via JR servo leads.
- Power Distribution Boards (PDB): Designed for direct soldering to high-current multi-rotor power distribution hubs.
- FPV Video Transmission Rigs: Utilizes the 12V auxiliary output to power clean analog and digital video transmitters (VTX).
Applications
This heavy-duty 60A brushless speed controller is an essential power regulation and motor control component across numerous professional and hobbyist unmanned systems.
- Heavy-Lift Aerial Filming Multirotors: Reliable speed controller for cinema-grade drones carrying heavy mirrorless and RED camera gimbals.
- Agricultural Spraying Hexacopters & Octocopters: High-current motor control for commercial crop-spraying UAVs operating in demanding outdoor environments.
- Industrial Inspection Drones: Power-dense ESC for long-range mapping and infrastructure surveillance multi-rotors.
- FPV Freestyle & Cinematic Long-Range Rigs: Delivers instantaneous throttle response and high burst current for 7-inch to 10-inch long-range cruisers.
- Search & Rescue (SAR) UAVs: Dependable thermal and signal-safe motor control for emergency deployment drones.
- Large Fixed-Wing Powered Gliders: High-power motor control for large electric sailplanes and motor gliders.
- Autonomous Delivery Drones: Robust speed controller for last-mile autonomous cargo transport multi-rotors.
- Unmanned Surface Vehicles (USV): High-amperage motor drive for remote-controlled aquatic surface rovers and boats.
- Autonomous Mobile Robots (AMR): Heavy-duty motor control for high-torque industrial robotic drive wheels.
- Propulsion R&D Test Benches: Precision motor speed control for university and laboratory dynamometer testing rigs.
- STEM Educational Advanced Robotics: Professional-grade motor controller for student-built heavy robotics projects.
- Custom Electric Propulsion Rigs: Reliable high-current ESC for custom electric mobility and propulsion prototypes.
Package Includes
- 1 × ZTW Spider Series 60A OPTO Brushless ESC (Model: ZTW-SPIDER-60A) with JR Servo Lead
Note: Battery and motor bullet connectors are not included in the package and must be soldered separately by the user according to setup requirements.
Product Specifications
| Parameter | Specification |
|---|---|
| Brand / Distributor | SPIDER Automation |
| Manufacturer / Series | ZTW Spider Series |
| Model Number | ZTW-SPIDER-60A |
| Product Type | OPTO Brushless Electronic Speed Controller (ESC) |
| Firmware Type | Pre-Flashed SimonK OneShot125 Factory Firmware |
| Burst Current Rating | 60 A |
| Input Voltage Range | 7.4 V to 22.2 V DC |
| Supported Battery Chemistries | 2S to 6S LiPo / Li-ion Battery Packs |
| BEC Type | OPTO Isolated (No Internal Linear BEC) |
| Auxiliary Output Voltage | 12 V DC Regulated Output for Peripherals |
| Signal Lead Type | JR-Type Standard Servo Signal Cable |
| Safety Features | Thermal overload protection, auto throttle shutdown on signal loss, safe-start arming |
| Programming Method | Transmitter Throttle Stick Programming |
| Operating Temperature Range | -20°C to +85°C |
| Physical Dimensions (L × W × H) | 55 mm × 30 mm × 13 mm |
| Product Net Weight | 48 g |
| Shipping Package Weight | 0.080 kg (80 grams) |
| Shipping Dimensions (L × W × H) | 10 cm × 5 cm × 3 cm |
Installation & Setup Guidelines
Standard electrical soldering and ESC calibration procedures must be observed when installing the ZTW Spider 60A speed controller.
- Connector Solder Preparation: Solder appropriate high-current power connectors (such as XT60/XT90) to the input power leads and gold bullet connectors to the three motor output wires. Ensure all joints are insulated with heat-shrink tubing.
- Signal Connection: Plug the JR-type servo lead into the designated motor output channel on your flight controller or RC receiver. Since the ESC is OPTO isolated, ensure your receiver/flight controller is powered by a separate BEC or power module.
- Throttle Range Calibration: Prior to first flight, perform a throttle range calibration via your radio transmitter and flight control software to synchronize minimum and maximum PWM pulse widths (typically 1000µs to 2000µs).
- Safe Arming Verification: Verify that the motor refuses to spin when the throttle stick is at zero position during startup, confirming proper safe-start arming interlock operation.
- Thermal Placement: Mount the ESC in a location with adequate airflow inside the aircraft fuselage or carbon frame to optimize thermal dissipation during high-ampere operations.