
SPIDER Automation | A2212 1400KV Brushless Motor + SimonK 30A ESC + HD 1045 Propeller Combo | Four-Motor Drone Propulsion System
Description
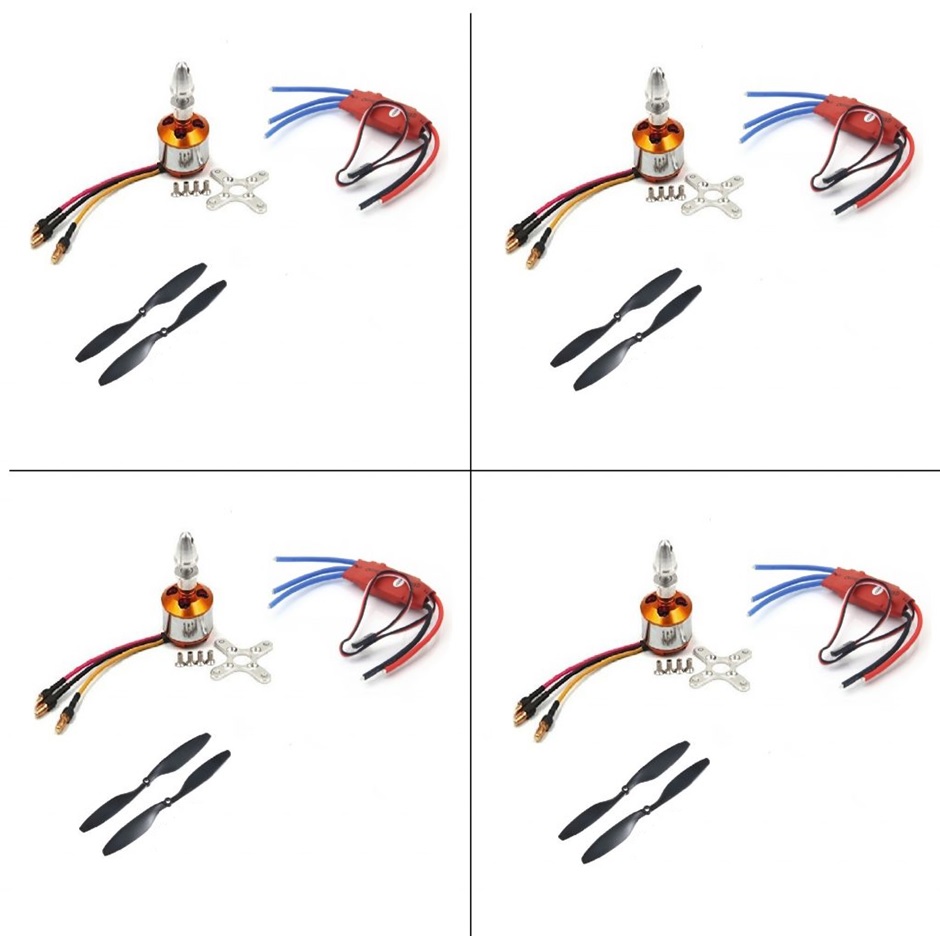
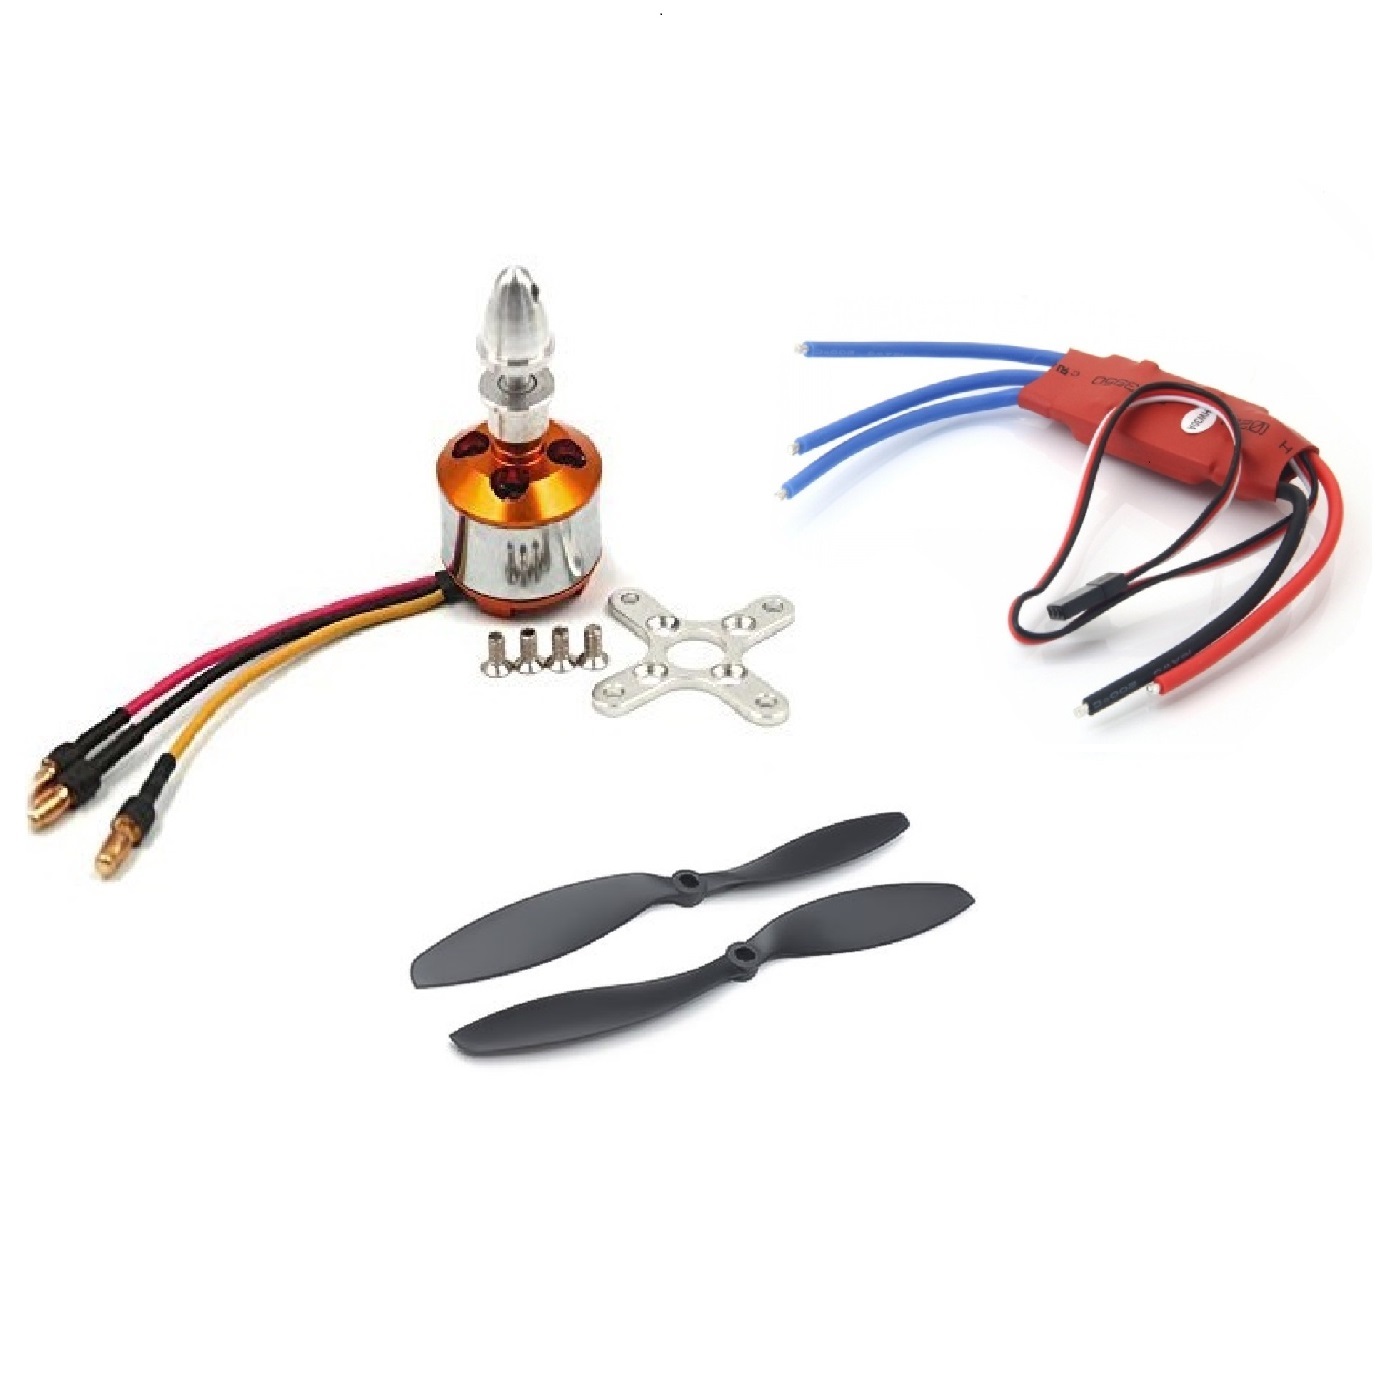
The A2212 1400KV BLDC Brushless Motor, SimonK 30A ESC and HD 1045 Propeller Combo Set is a coordinated propulsion package designed for compatible quadcopters and multirotor aircraft. The package contains four brushless motors, four electronic speed controllers, four motor accessory sets and four pairs of HD 1045 propellers, providing the principal propulsion components for a four-motor aircraft configuration.
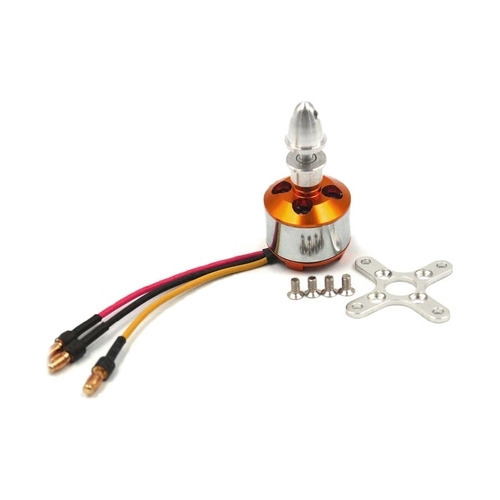
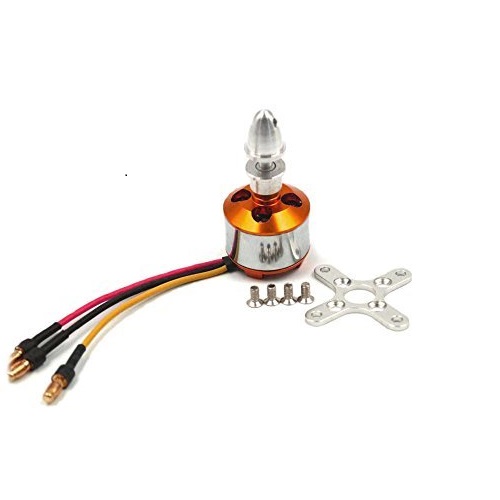
Each A2212 motor has a 1400KV rating, 180W maximum power rating and 80% maximum efficiency specification. The motors are specified for 2S–3S LiPo battery systems and feature a 14-pole configuration, 65mΩ internal resistance and a 3.17mm shaft. Pre-soldered 3.5mm connectors simplify connection to compatible ESC motor outputs.
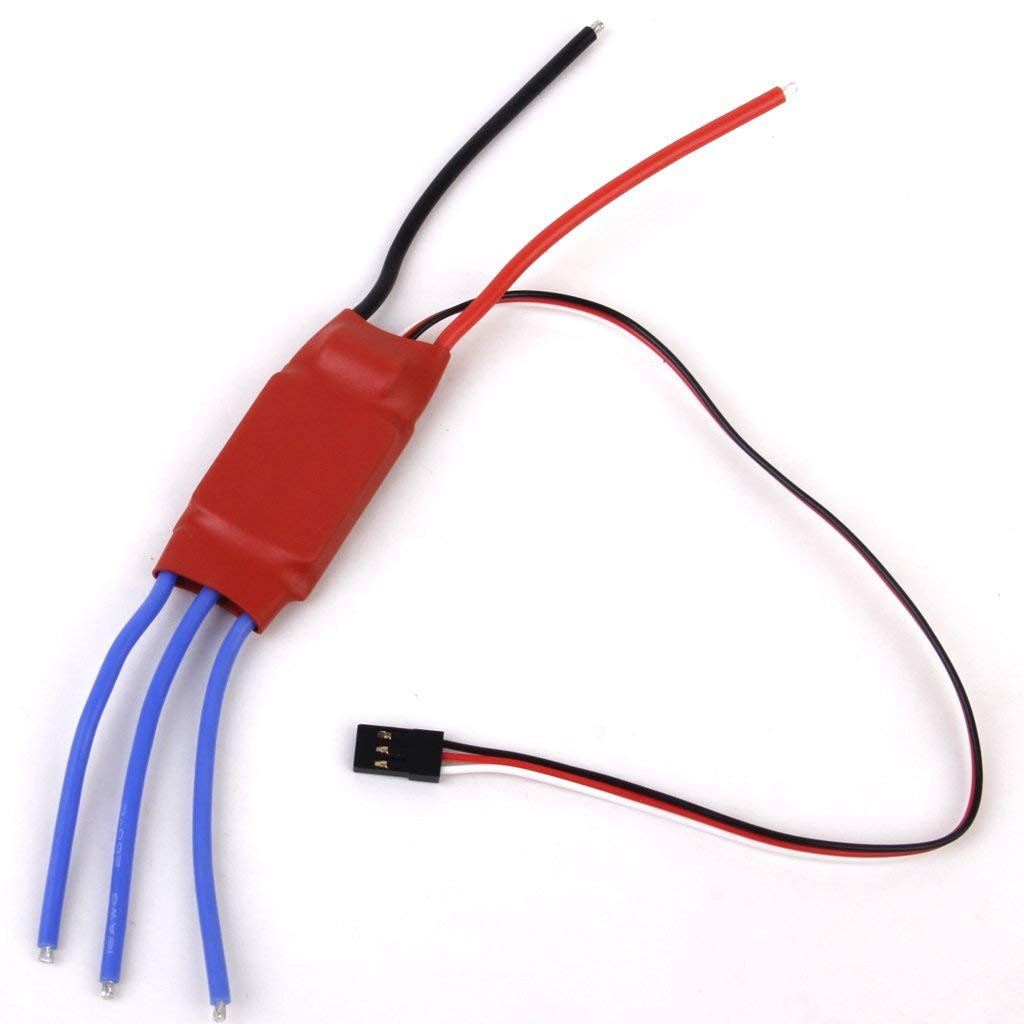
The package also includes four SimonK 30A brushless ESCs, each with a stated 30A constant-current rating and onboard 3A BEC. The HD 1045 propeller sets feature 10-inch diameter, 4.5-inch pitch and ABS construction. These components are intended to be configured together as a propulsion system, with battery capability, propeller loading, ESC ratings and aircraft requirements considered during installation.
A2212 1400KV Brushless Motor Design & Performance
The A2212 is a brushless DC outrunner motor intended for multirotor and RC aircraft propulsion. Its 1400KV rating, 14-pole construction and electrical specifications provide the main reference values for motor and propeller matching.
- 1400KV Motor Rating: Defines the motor’s nominal rotational speed constant in RPM per volt under specified no-load conditions; it is not a guaranteed loaded operating speed.
- 180W Maximum Power: The source lists 180W as the maximum motor power rating. Actual power demand depends on battery voltage, propeller loading and operating conditions.
- Maximum Efficiency: The motor is listed with a maximum efficiency of 80%.
- Current Capacity: The source lists 16A for 60 seconds. This is a time-qualified rating and should not be interpreted as an unrestricted continuous-current specification.
- No-Load Current: Listed as 0.7A at 10V.
- Maximum Efficiency Current: The specified operating-current range at maximum efficiency is 6–12A.
- Internal Resistance: The motor has a listed internal resistance of 65mΩ.
- 14-Pole Configuration: The motor specification identifies 14 poles.
- Metal Housing: A metal external case provides the motor’s mechanical enclosure.
- Pre-Soldered Connectors: Supplied with 3.5mm connectors for motor-to-ESC connection.
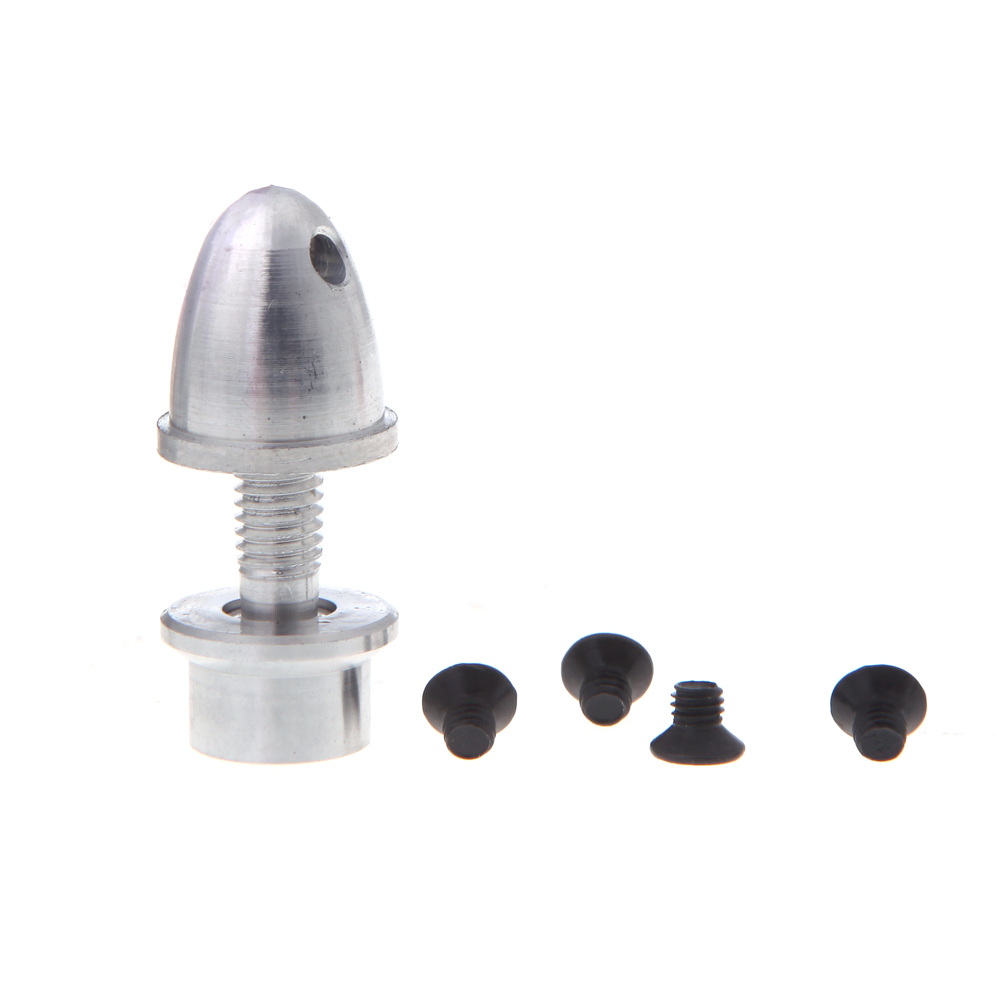
- 3.17mm Shaft: Provides the stated shaft dimension for compatible propeller adapters.
- Bidirectional Rotation: The motor can operate in CW or CCW rotation when its three-phase connection sequence is configured appropriately through the ESC.
SimonK 30A Brushless Electronic Speed Controller
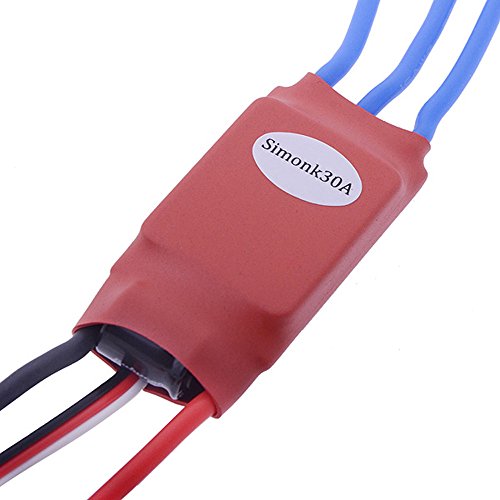
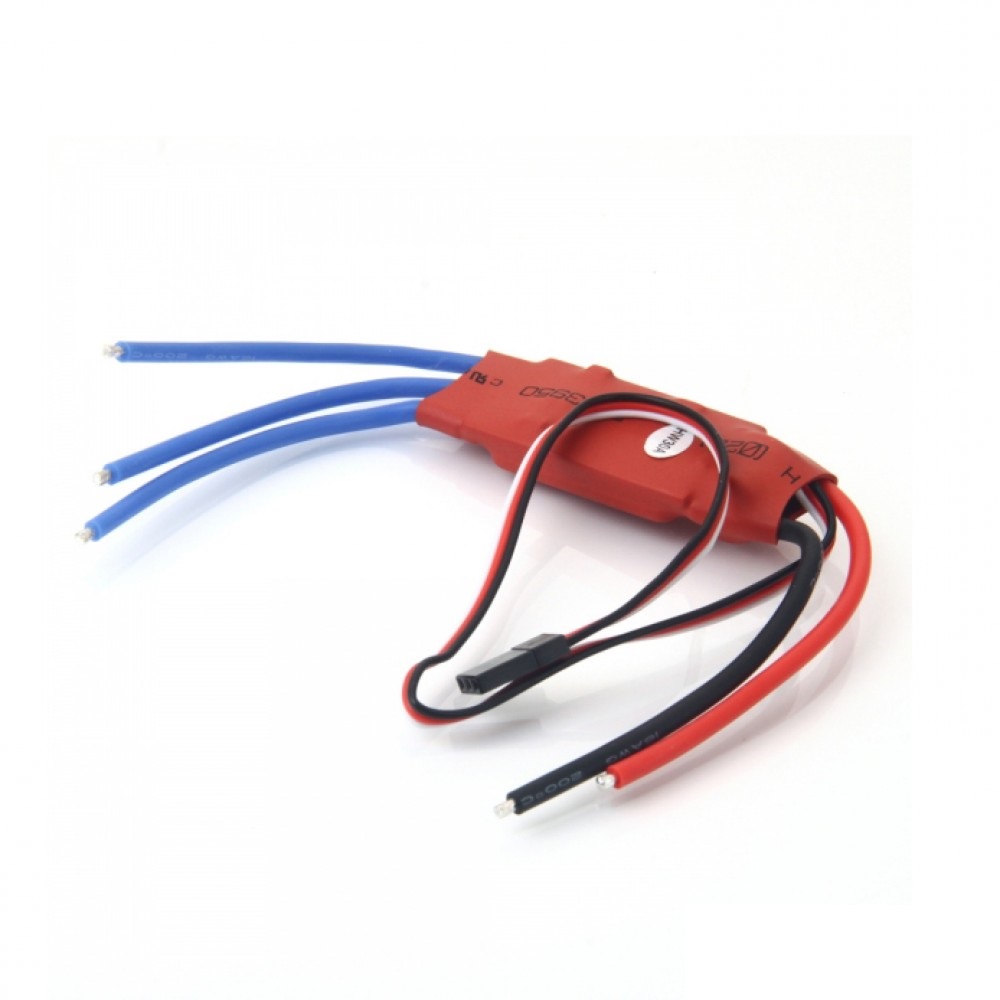
Four SimonK 30A brushless electronic speed controllers are included, with one ESC intended for each motor. An ESC controls brushless motor phase switching and speed in response to its control input. The onboard BEC provides a supply for compatible low-voltage control electronics, subject to its actual output-voltage specification.
- 30A Constant-Current Rating: Each ESC is listed with a constant-current rating of 30A.
- 40A Maximum Current: A maximum-current rating of 40A is listed. The source does not clarify the permitted duration or test conditions.
- Onboard BEC: Each ESC includes a BEC with a stated 3A output-current rating.
- 2S–3S LiPo Compatibility: The ESC specification lists compatibility with 2S–3S LiPo batteries.
- SimonK Firmware: Identified as the ESC firmware platform in the supplied product description.
- Motor Speed Control: Provides electronic control of the connected brushless motor.
- Four-ESC Configuration: Four ESC units are included for the four-motor package.
HD 1045 Propeller Design & Configuration
The package includes HD 1045 black ABS propellers intended for compatible multirotor propulsion assemblies. The 1045 designation corresponds to a 10-inch propeller diameter and 4.5-inch pitch. The supplied propeller description identifies CW and CCW blades, allowing the required rotation directions to be selected for a compatible multirotor layout.
- Propeller Model: HD 1045.
- Diameter: 10 inches (254mm).
- Pitch: 4.5 inches.
- Material: ABS plastic.
- Colour: Black.
- Rotation Configuration: CW and CCW propeller blades are identified in the supplied set description.
- Listed Weight: 22g per pair, as stated in the source.
- Hub Interface Measurements: Source lists 7mm for the flat-side measurement and 8mm for the round-side measurement. Confirm the actual hub interface before installation.
- Propeller Quantity: Four pairs are indicated in the package description.
Motor Rotation & ESC Configuration
The A2212 brushless motor can operate in either rotational direction when its three-phase connection sequence is configured appropriately through the ESC. To reverse the rotation of a conventional three-phase brushless motor, swap any two of the three motor phase wires. Reversing the battery supply polarity is not the correct method and can damage the ESC.
- CW Operation: Configure the motor phase sequence and propeller orientation for clockwise rotation.
- CCW Operation: Reverse motor rotation by swapping any two of the three phase connections or by using a supported ESC configuration method.
- Propeller Matching: Install the corresponding CW or CCW propeller according to the aircraft’s motor layout.
- ESC Assignment: Connect one compatible ESC to each motor and configure the control system for the intended aircraft layout.
Applications
This four-motor propulsion package is intended for compatible RC aircraft and multirotor platforms. Final suitability depends on the aircraft’s frame, take-off weight, propeller clearance, battery discharge capability, ESC installation and required thrust.
- Quadcopter Builds: Four-motor propulsion integration for compatible quadcopter frames.
- Q450-Class Quadcopter Platforms: Propulsion-system development for compatible frame configurations, subject to propeller clearance and load requirements.
- Multirotor Aircraft: Motor, ESC and propeller integration in compatible multi-motor aerial platforms.
- Hexacopter Development: Individual motor and ESC components can be used in suitable six-motor configurations, although this four-motor package does not provide a complete hexacopter set.
- RC Airplanes: Brushless motor and ESC components for compatible fixed-wing propulsion systems with suitable propeller selection.
- UAV Prototypes: Propulsion component integration in compatible unmanned aerial vehicle development platforms.
- Custom Drone Development: Building multirotor propulsion systems using A2212-class brushless motors.
- Aircraft Powertrain Prototyping: Evaluation of motor, ESC, battery and propeller combinations.
- Flight Controller Integration: Use with compatible multirotor flight controllers and ESC control outputs.
- Brushless ESC Evaluation: Testing and configuration of brushless electronic speed controllers in compatible aircraft systems.
- Propeller Performance Testing: Evaluation of 1045 propeller configurations under controlled operating conditions.
- Motor Rotation Configuration: Testing CW and CCW motor arrangements in multirotor propulsion layouts.
- Replacement Propulsion Assemblies: Replacing compatible A2212 motors, ESCs and propellers in existing aircraft systems.
Package Includes
- 4 × A2212 10T/13T 1400KV Brushless Motors with Pre-Soldered Connectors
- 4 × Sets Motor Accessories
- 4 × SimonK 30A Brushless Electronic Speed Controllers
- 4 Pairs HD 1045 ABS Propellers – CW and CCW Blades
Product Specifications
A2212 1400KV Brushless Motor
| Parameter | Specification |
|---|---|
| Motor Model | A2212 10T/13T |
| Motor Type | BLDC Brushless Motor |
| Motor KV Rating | 1400KV |
| Maximum Efficiency | 80% |
| Current Capacity | 16A for 60 seconds |
| No-Load Current | 0.7A at 10V |
| Maximum Efficiency Current | 6–12A |
| Maximum Power | 180W |
| Internal Resistance | 65mΩ |
| Number of Poles | 14 |
| Motor Connector | 3.5mm pre-soldered connectors |
| Shaft Diameter | 3.17mm |
| Compatible Battery | LiPo |
| Battery Configuration | 2S–3S |
| Motor Length | 27.5mm |
| Motor Width | 26.5mm |
| Motor Weight | 62g per motor |
| Housing Material | Metal |
| Rotation Capability | CW or CCW through three-phase connection configuration |
SimonK 30A Electronic Speed Controller
| Parameter | Specification |
|---|---|
| ESC Type | Brushless Electronic Speed Controller |
| Firmware | SimonK |
| Constant Current Rating | 30A |
| Maximum Current | 40A; duration and test conditions not stated |
| BEC Current Rating | 3A |
| Compatible Battery | LiPo |
| Battery Configuration | 2S–3S |
| ESC Quantity | 4 units |
HD 1045 Propellers
| Parameter | Specification |
|---|---|
| Propeller Model | HD 1045 |
| Propeller Type | Multirotor Propeller |
| Diameter | 10 inches (254mm) |
| Pitch | 4.5 inches |
| Material | ABS Plastic |
| Colour | Black |
| Rotation Configuration | CW and CCW blades |
| Listed Weight | 22g per pair |
| Hub Interface Measurements | 7mm flat-side and 8mm round-side measurements, as listed; verify actual hub geometry |
| Package Quantity | 4 pairs |
Connection & Operating Recommendations
- Verify Motor and ESC Compatibility: Confirm that the ESC input-voltage range and current capability are suitable for the motor and selected 2S–3S battery configuration.
- Observe Current Limits: The motor’s 16A rating is specified for 60 seconds. Do not assume it is a continuous-current rating. Keep actual motor loading within applicable limits.
- Configure Motor Rotation Correctly: Reverse rotation by swapping any two of the three motor phase wires or by using a supported ESC configuration method. Never reverse battery polarity to change motor direction.
- Match CW and CCW Propellers: Install the correct propeller orientation for each motor position according to the flight-controller configuration.
- Check Propeller Hub Fit: Verify the propeller adapter dimensions against the actual motor shaft and propeller hub before installation.
- Secure Propellers: Ensure that all propellers and adapters are properly tightened and free from cracks or deformation.
- Check BEC Output Voltage: Confirm the ESC BEC voltage is compatible with the flight controller, receiver and other connected electronics before supplying power.
- Manage BEC Connections: When using multiple ESCs with onboard BECs, follow the flight-controller manufacturer’s power-input and wiring instructions. Do not assume all BEC outputs should be connected in parallel.
- Verify ESC Firmware: Confirm ESC hardware and firmware compatibility before attempting firmware changes or programming.
- Check Motor Mounting: Ensure the motors are firmly installed and the propellers have adequate clearance from the frame.
- Inspect Electrical Connections: Check all bullet connectors, solder joints and power wiring for secure contact and suitable current capacity.
- Conduct Controlled Testing: Check motor direction without propellers first. Perform subsequent propeller tests in a controlled area with appropriate precautions.
- Monitor Operating Temperature: Check motor and ESC temperatures during initial operation, especially under high propeller loading.