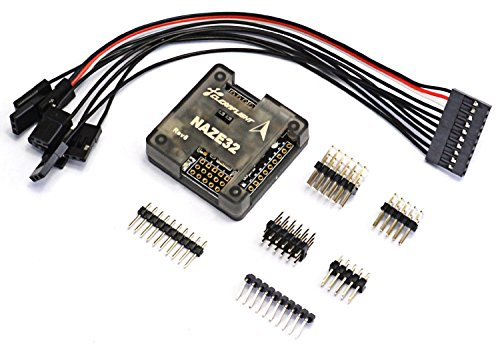

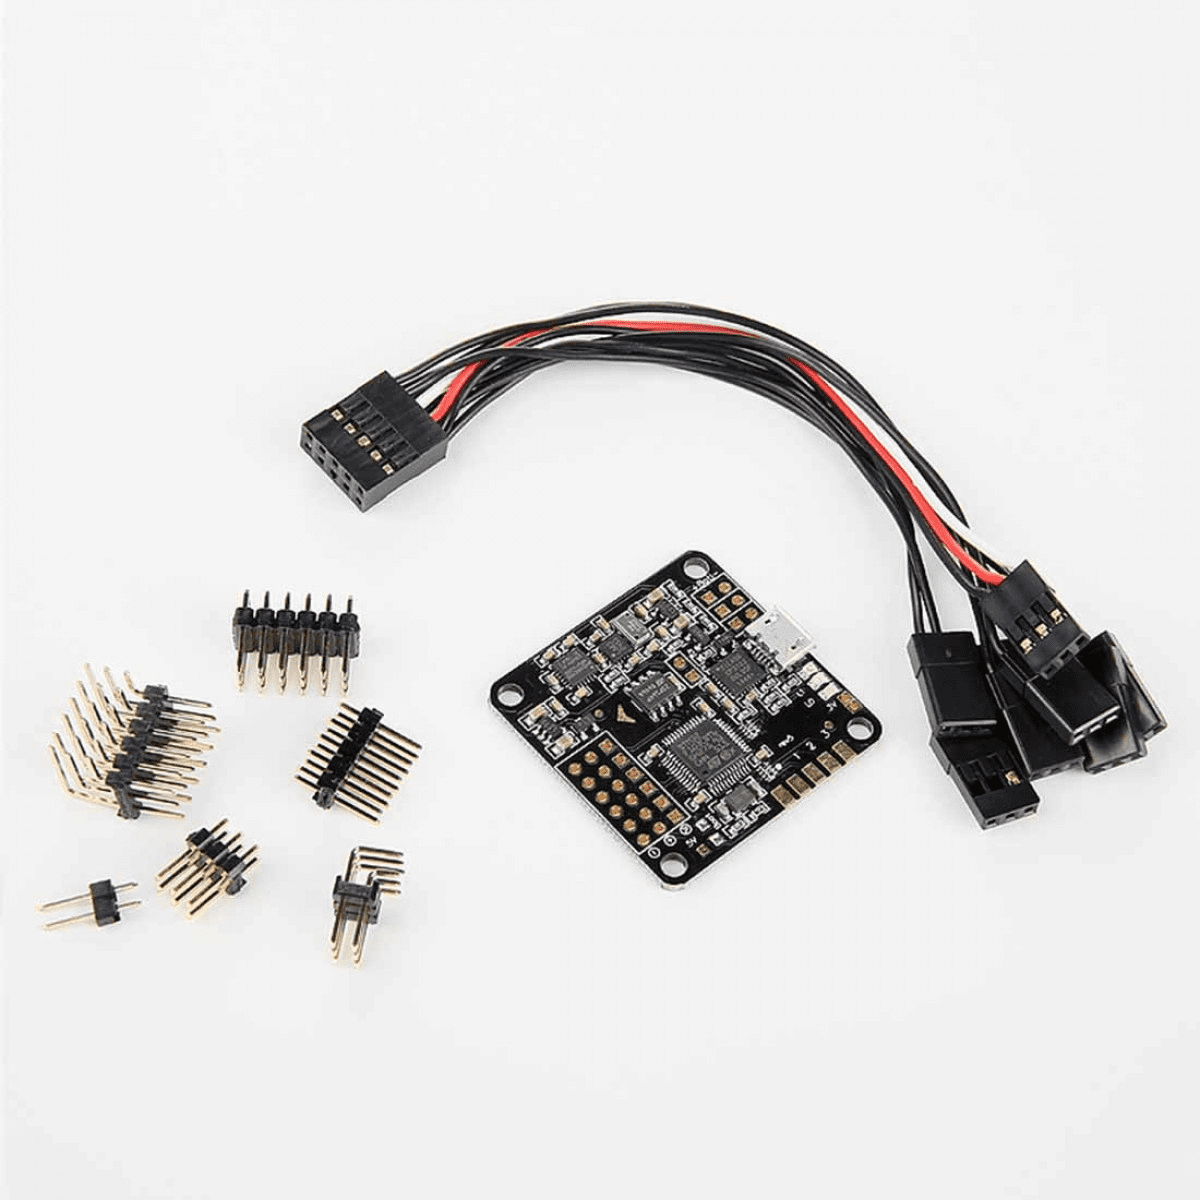


SPIDER Automation Naze32 6DOF Flight Controller | STM32F103, MPU6500 IMU & USB Configuration
The SPIDER Automation Naze32 6DOF Flight Controller is a compact flight-control board designed for multirotor aircraft and FPV applications requiring essential inertial sensing, flight stabilisation and receiver-system integration. It uses an STM32F103 32-bit microcontroller operating at 72MHz and an MPU6500 6-axis inertial measurement unit (IMU), combining gyroscope and accelerometer functions on a single board.
The 6DOF configuration provides the core motion-sensing hardware required by compatible flight-control firmware without a dedicated magnetometer or barometer in its stated hardware configuration. The board supports a 3.3V–5V DC supply, onboard USB connectivity, battery-voltage monitoring and an integrated FrSky telemetry converter. Configuration is supported through compatible Baseflight Configurator software within the Naze firmware ecosystem.
With a 36 × 36 × 7mm PCB format, the Naze32 6DOF is intended for compact flight-control installations where essential IMU-based stabilisation and configuration functions are required without the additional sensor hardware of higher-sensor-count flight-controller variants.
Key Features
- 6DOF Flight-Control Configuration: Provides gyroscope and accelerometer sensing without a dedicated magnetometer or barometer in the stated hardware configuration.
- STM32F103 Processor: Uses a 32-bit microcontroller operating at 72MHz for flight-control processing.
- MPU6500 Inertial Measurement Unit: Combines 3-axis gyroscope and 3-axis accelerometer functions.
- 3.3V–5V DC Operating Supply: Designed for compatible low-voltage flight-controller power systems.
- USB Configuration Interface: Enables computer connectivity for supported setup and configuration operations.
- Baseflight Configurator: Supports graphical configuration through compatible Baseflight software.
- Battery Voltage Monitoring: Provides battery-voltage monitoring functionality for compatible configurations.
- FrSky Telemetry Conversion: Includes a built-in telemetry converter for compatible FrSky systems.
- Naze Firmware: Uses the Naze flight-control firmware platform.
- 36 × 36mm Board Format: Compact PCB footprint for compatible multirotor frame installations.
- Unsoldered Connection Hardware: Supplied with Berg pins and cables for installation.
STM32F103 Processor & Flight-Control Architecture
The Naze32 6DOF is built around an STM32F103 32-bit microcontroller operating at 72MHz. The processor provides the computational platform for compatible Naze firmware, handling flight-control calculations, inertial sensor data and supported receiver and telemetry functions.
- Microcontroller: STM32F103.
- Processor Architecture: 32-bit.
- Operating Frequency: 72MHz.
- Firmware Platform: Naze firmware.
- Configuration Software: Compatible Baseflight Configurator.
MPU6500 6-Axis IMU & Motion Sensing
The integrated MPU6500 6-axis IMU combines a three-axis gyroscope and a three-axis accelerometer. These sensing elements provide the motion data required by compatible flight-control firmware for rotational-rate measurement, acceleration sensing and aircraft attitude estimation.
- Gyroscope: Three-axis angular-motion sensing.
- Accelerometer: Three-axis acceleration sensing.
- IMU Model: MPU6500.
- Sensor Configuration: 6-axis inertial measurement.
- Flight-Control Function: Supplies motion measurements for supported stabilisation algorithms.
6DOF Configuration Compared with 10DOF Flight Controllers
The Naze32 6DOF version is intended for flight-control installations that require gyroscope and accelerometer sensing without the additional dedicated compass and barometric sensors associated with 10DOF configurations. This distinction is important when selecting a flight controller according to the required navigation, heading-reference and altitude-estimation functions.
- 6DOF Sensor Set: Gyroscope and accelerometer functions through the MPU6500 IMU.
- Magnetometer: No dedicated magnetometer is included in the stated 6DOF hardware configuration.
- Barometer: No dedicated barometer is included in the stated 6DOF hardware configuration.
- Navigation Requirements: Applications requiring compass-based heading or barometric altitude measurements need the corresponding additional sensor hardware.
USB Connectivity & Flight Controller Configuration
The onboard USB interface provides a direct connection to a compatible computer for flight-controller setup and configuration. The board is designed to work with compatible Baseflight Configurator software, allowing supported firmware settings and flight-control parameters to be managed through a graphical interface.
- USB Interface: Onboard USB connectivity.
- Configuration Software: Baseflight Configurator.
- Firmware Ecosystem: Naze firmware.
- Setup Function: Computer-based configuration through compatible software.
Battery Voltage Monitoring & FrSky Telemetry
The board incorporates battery-voltage monitoring functionality and a built-in FrSky telemetry converter. These features support compatible battery-monitoring and telemetry arrangements within the flight-control system. Actual telemetry availability depends on the connected receiver, wiring configuration and installed firmware support.
- Battery Monitoring: Supports battery-voltage monitoring in compatible configurations.
- Telemetry Converter: Integrated FrSky telemetry conversion hardware.
- Receiver Integration: Intended for compatible FrSky telemetry arrangements.
- Firmware Dependency: Telemetry functions depend on suitable firmware settings and compatible connected equipment.
PCB Design & Installation Format
The Naze32 6DOF uses a 36 × 36mm PCB footprint with a board thickness of 7mm. The package includes unsoldered Berg pins and connecting cables, allowing the installer to prepare the required connections according to the aircraft wiring layout.
- PCB Length: 36mm.
- PCB Width: 36mm.
- Board Height: 7mm.
- Connection Hardware: Berg pins and cables supplied unsoldered.
- MicroSD Slot: Not available.
Applications
- FPV Multirotor Aircraft: Flight-control integration for compatible FPV multirotor platforms.
- Quadcopter Flight Control: IMU-based stabilisation for compatible quadcopter configurations.
- Multirotor Stabilisation Systems: Motion-sensing and flight-control processing using the integrated 6-axis IMU.
- Manual Flight-Control Systems: Applications using compatible Naze firmware and supported pilot-control configurations.
- Acro Flight Configurations: Flight-control installations using supported rate-based control modes.
- USB-Based Configuration: Computer-connected setup and parameter adjustment through compatible software.
- Battery Monitoring Systems: Flight-control installations using the integrated battery-voltage monitoring function.
- FrSky Telemetry Integration: Compatible radio-control systems using the onboard telemetry converter.
- Compact Flight Electronics: Space-conscious aircraft installations requiring a 36 × 36mm flight-controller board.
- Naze Firmware Platforms: Multirotor projects using compatible Naze firmware configurations.
- Baseflight Configuration Systems: Flight-controller setups managed through compatible Baseflight Configurator software.
- Flight-Control Development: Embedded flight-control installations using the STM32F103 processor and MPU6500 sensor platform.
Package Includes
- 1 × Naze32 6DOF Flight Controller Board
- 1 × Set of Berg Pins and Connecting Cables (unsoldered)
Product Specifications
| Parameter | Specification |
|---|---|
| Product Name | Naze32 6DOF Flight Controller |
| Product Type | Flight Controller Board |
| Version | 6DOF |
| Microcontroller | STM32F103 |
| Processor Architecture | 32-bit |
| Processor Frequency | 72MHz |
| IMU Sensor | MPU6500 |
| Sensor Configuration | 6DOF |
| Gyroscope | 3-axis |
| Accelerometer | 3-axis |
| Magnetometer | No dedicated magnetometer in the stated 6DOF configuration |
| Barometer | No dedicated barometer in the stated 6DOF configuration |
| Input Voltage | 3.3V–5V DC |
| Firmware | Naze Firmware |
| Configuration Software | Baseflight Configurator |
| USB Connectivity | Onboard USB interface |
| Battery Voltage Monitoring | Supported |
| FrSky Telemetry Converter | Built-in |
| MicroSD Card Slot | No |
| PCB Length | 36mm |
| PCB Width | 36mm |
| Board Height | 7mm |
Connection & Operating Recommendations
- Verify Supply Voltage: Use a regulated 3.3V–5V DC supply within the board’s specified operating range and confirm polarity before connecting power.
- Prepare the Berg Pins: The supplied Berg pins and cables are unsoldered. Install the required headers carefully according to the intended wiring arrangement.
- Check USB Connectivity: Use a suitable USB connection and compatible configuration software when setting up the board.
- Verify Firmware Compatibility: Confirm the firmware target and configurator compatibility before flashing or updating the board.
- Avoid Unverified Firmware Updates: Updating or flashing the default firmware may cause computer-connectivity problems. Confirm the correct firmware and recovery procedure before making changes.
- Configure Battery Monitoring: Verify the battery-voltage monitoring connection and firmware calibration before relying on voltage readings.
- Configure FrSky Telemetry: Confirm receiver compatibility, wiring and firmware settings before using the integrated telemetry converter.
- Account for the 6DOF Sensor Set: Do not rely on this board for onboard compass heading or dedicated barometric altitude measurements.
- Confirm Case Clearance: Check the installed enclosure and connector clearance before mounting the board inside the aircraft frame.
- Perform Bench Checks: Verify sensor operation, receiver response, battery monitoring and motor-output configuration without propellers before flight testing.