
SPIDER Automation KK2 Multi-Rotor LCD Flight Controller Board | MPU6050 6-Axis IMU & Atmel Mega644PA Processor
Description
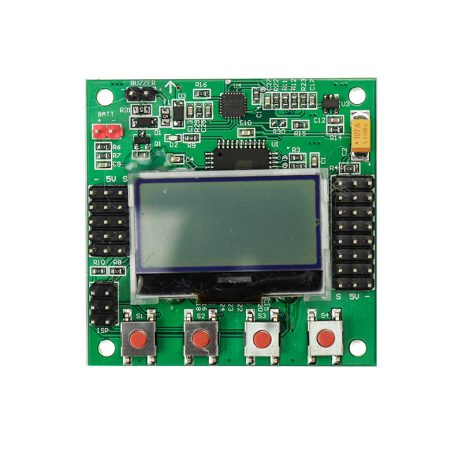
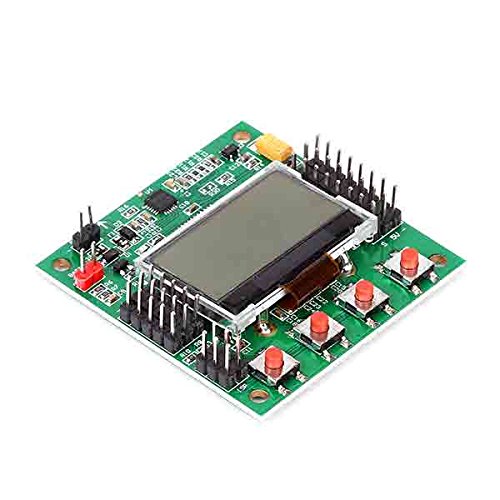
The KK2 Multi-Rotor LCD Flight Controller Board is an embedded flight-control system designed to manage stabilisation and control-signal mixing in multi-rotor aircraft and supported fixed-wing configurations. It combines an Atmel Mega644PA 8-bit AVR microcontroller with an MPU6050 6-axis inertial measurement sensor, integrating gyroscope and accelerometer measurements for flight-control processing. The onboard LCD and control buttons provide a convenient interface for configuring aircraft layouts, adjusting controller parameters and accessing firmware settings.
The integrated Auto-Level function uses motion-sensor information to assist with aircraft attitude stabilisation. Pre-installed KK2 firmware version 1.6 provides a selection of predefined aircraft configurations, while the Mixer Editor enables customised motor and servo signal mixing. This flexibility supports different airframe arrangements without requiring a separate flight-controller design for each configuration.
Operating from a 4.8–6.0V input supply, the controller accepts a five-channel receiver signal configuration and provides a standard 6-pin AVR interface for compatible programming equipment. A piezo buzzer is included for audible activation and deactivation feedback.
Key Features
- Integrated Flight-Control Processing: Atmel Mega644PA 8-bit AVR RISC microcontroller processes sensor information and executes the installed flight-control firmware.
- 6-Axis Inertial Measurement: MPU6050 combines three-axis gyroscope and three-axis accelerometer sensing for aircraft motion and orientation measurement.
- Auto-Level Capability: Provides assisted aircraft levelling through accelerometer-based orientation sensing and firmware processing.
- Onboard LCD Interface: Integrated display and button controls allow direct access to configuration and setup functions.
- Multiple Aircraft Layouts: Supports a broad range of multi-rotor arrangements, including + and X configurations.
- Custom Signal Mixing: Mixer Editor allows adjustment of motor and servo signal allocation, direction and mixing levels.
- Up to Eight Motor or Servo Outputs in Custom Mixes: Firmware mixer configuration supports aircraft designs using up to eight motor or servo outputs.
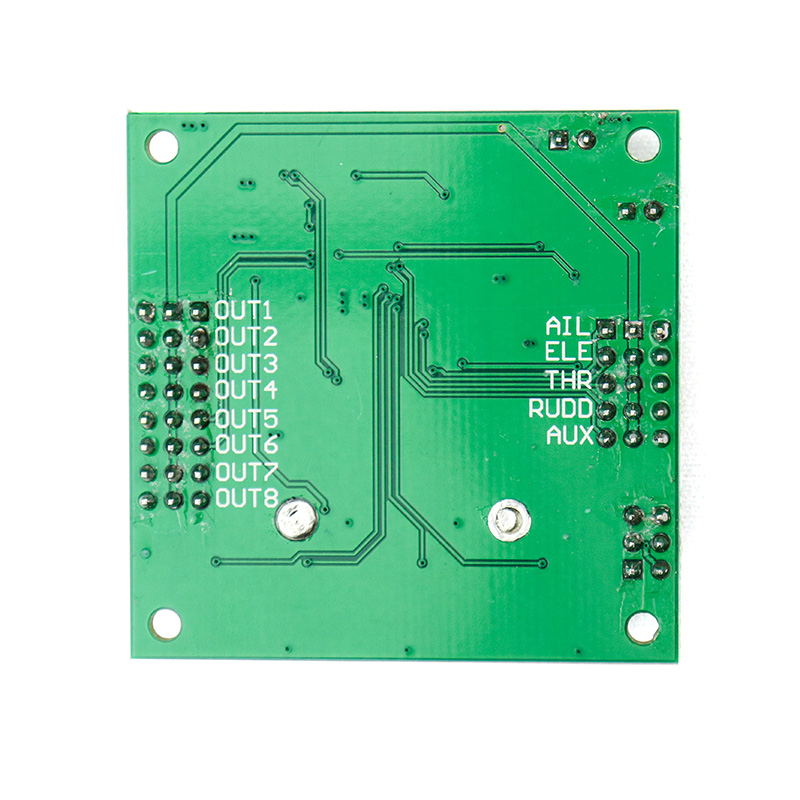
- Receiver Connectivity: Supports a five-channel receiver input configuration with a 1520µs signal specification.
- Standard AVR Interface: Provides a 6-pin AVR programming connection for compatible firmware tools.
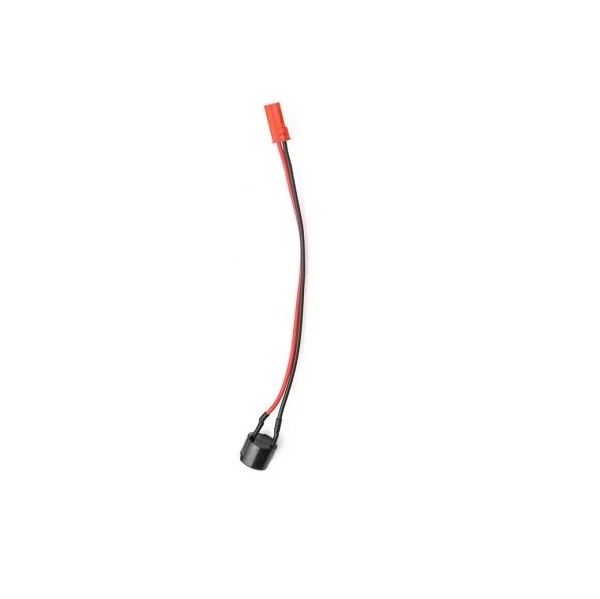
- Audible Activation Feedback: Included piezo buzzer provides audio indication during controller activation and deactivation.
- Pre-Installed Firmware: Supplied with KK2 firmware version 1.6 and predefined aircraft configuration options.
Flight Configuration & Firmware Support
The installed KK2 firmware provides predefined mixer layouts for different aircraft architectures. These configurations determine how receiver commands and sensor feedback are translated into motor or servo control signals.
Supported predefined configurations include:
- Dualcopter
- Tricopter
- Y6 multirotor
- Quadcopter +
- Quadcopter X
- Hexacopter +
- Hexacopter X
- Octocopter +
- Octocopter X
- X8 +
- X8 X
- H8
- H6
- V8
- V6
- Flying Wing
- Singlecopter 2M 2S
- Singlecopter 1M 4S
The Mixer Editor provides additional configuration flexibility by allowing the user to adjust how motor or servo outputs respond to receiver stick inputs and sensor signals. This enables customised mixing arrangements for supported aircraft designs, with up to eight motor or servo outputs available within the custom mixer configuration.
Sensor & Flight Stabilisation System
The onboard MPU6050 6-axis motion sensor integrates a three-axis gyroscope and a three-axis accelerometer. The gyroscope measures rotational movement, while the accelerometer provides linear acceleration and gravity-referenced orientation information. The flight-control firmware processes these measurements to support stabilisation and the Auto-Level function.
- Gyroscope Measurement: Detects rotational movement around the three principal axes for flight-control response.
- Accelerometer Measurement: Provides acceleration and orientation-related information used by the Auto-Level function.
- Combined Motion Sensing: Integrates gyroscope and accelerometer data within the flight-control system.
- Firmware-Based Stabilisation: Processes sensor measurements together with receiver commands to generate the required control outputs.
LCD Interface & Configuration
The integrated LCD and onboard buttons provide a local configuration interface for the KK2 flight controller. Users can access firmware menus, select aircraft layouts and adjust available mixer and flight-control settings directly on the board. This interface simplifies initial configuration and routine parameter adjustments without relying exclusively on a computer-based setup utility.
Applications
- Quadcopter Flight-Control Systems: Flight stabilisation and motor mixing for + and X quadcopter configurations.
- Tricopter Platforms: Flight-control configuration for three-motor aircraft with supported servo-based control arrangements.
- Hexacopter Systems: Control-signal mixing for six-motor + and X aircraft layouts.
- Octocopter Platforms: Firmware-based control configuration for eight-motor aircraft arrangements.
- Y6 Multirotors: Flight-control support for Y6 coaxial multirotor configurations.
- X8 Aircraft: Mixer configuration for X8 coaxial multi-rotor arrangements.
- Dualcopter Systems: Supported dualcopter flight-control configuration.
- Flying-Wing Aircraft: Firmware configuration for supported flying-wing control layouts.
- Singlecopter Platforms: Support for the listed singlecopter mixer configurations.
- Custom Multi-Rotor Airframes: Custom motor and servo signal mixing for compatible aircraft arrangements.
- Flight-Control Development: Evaluation of gyroscope, accelerometer and embedded flight-control processing.
- Embedded Control-System Testing: Testing of receiver input processing, sensor feedback and motor-control signal mixing.
Package Includes
- 1 × KK2 Multi-Rotor LCD Flight Control Board with MPU6050 and Atmel Mega644PA
- 1 × Piezo Buzzer
Product Specifications
| Parameter | Specification |
|---|---|
| Product Type | Multi-rotor flight controller board |
| Model | KK2 |
| Main Microcontroller | Atmel Mega644PA |
| Processor Architecture | 8-bit AVR RISC |
| Processor Memory | 64KB |
| Motion Sensor | MPU6050 |
| Sensor Configuration | 6-axis: 3-axis gyroscope and 3-axis accelerometer |
| Flight Assistance | Auto-Level |
| Display | Integrated LCD |
| User Interface | Onboard buttons and LCD menu |
| Input Voltage | 4.8–6.0V DC |
| Receiver Input Configuration | 5-channel receiver signal configuration |
| Receiver Signal Specification | 1520µs |
| Programming Interface | Standard 6-pin AVR interface |
| Firmware | KK2 firmware version 1.6, pre-installed |
| Mixer Configuration | Predefined layouts and custom Mixer Editor |
| Custom Mixer Output Support | Up to 8 motor or servo outputs in supported custom configurations |
| Aircraft Configuration Support | Dualcopter, Tricopter, Y6, Quadcopter, Hexacopter, Octocopter, X8, H8, H6, V8, V6, Flying Wing and Singlecopter layouts |
| Audible Indicator | Included piezo buzzer |
| Button Colour Variants | Black or pink buttons |
Connection & Operating Recommendations
- Verify Supply Voltage: Operate the flight controller within its specified 4.8–6.0V DC input range. Do not connect a battery or power source that exceeds this range.
- Check Receiver Configuration: Confirm the receiver output arrangement and channel assignments before connecting the receiver to the flight controller.
- Confirm Signal Compatibility: The stated receiver configuration uses a 1520µs signal specification. Verify compatibility with the selected receiver and firmware configuration.
- Secure Sensor Mounting: Install the controller firmly on the aircraft frame and minimise unwanted vibration or movement that could affect inertial sensor measurements.
- Calibrate Before Operation: Complete the required sensor calibration and aircraft setup procedures on a stable, level surface before attempting flight.
- Verify Mixer Settings: Select the correct aircraft layout and confirm motor or servo output assignments, rotation directions and control responses before connecting propellers.
- Check Motor Response: Test receiver inputs and motor-control outputs with propellers removed to verify correct channel mapping and stabilisation response.
- Use Compatible AVR Equipment: Firmware programming requires a compatible 6-pin AVR programming interface and the correct firmware for the KK2 hardware.
- Verify Firmware Compatibility: Confirm that any firmware update is intended for the KK2 board and its hardware revision. Firmware versions and configuration files intended for other flight-controller models may not be compatible.
- Check Buzzer Operation: Connect the included piezo buzzer to its intended connection before relying on audible activation or deactivation feedback.
- Complete a Ground Check: Verify controller orientation, sensor calibration, receiver response, motor order and failsafe behaviour before flight operation.